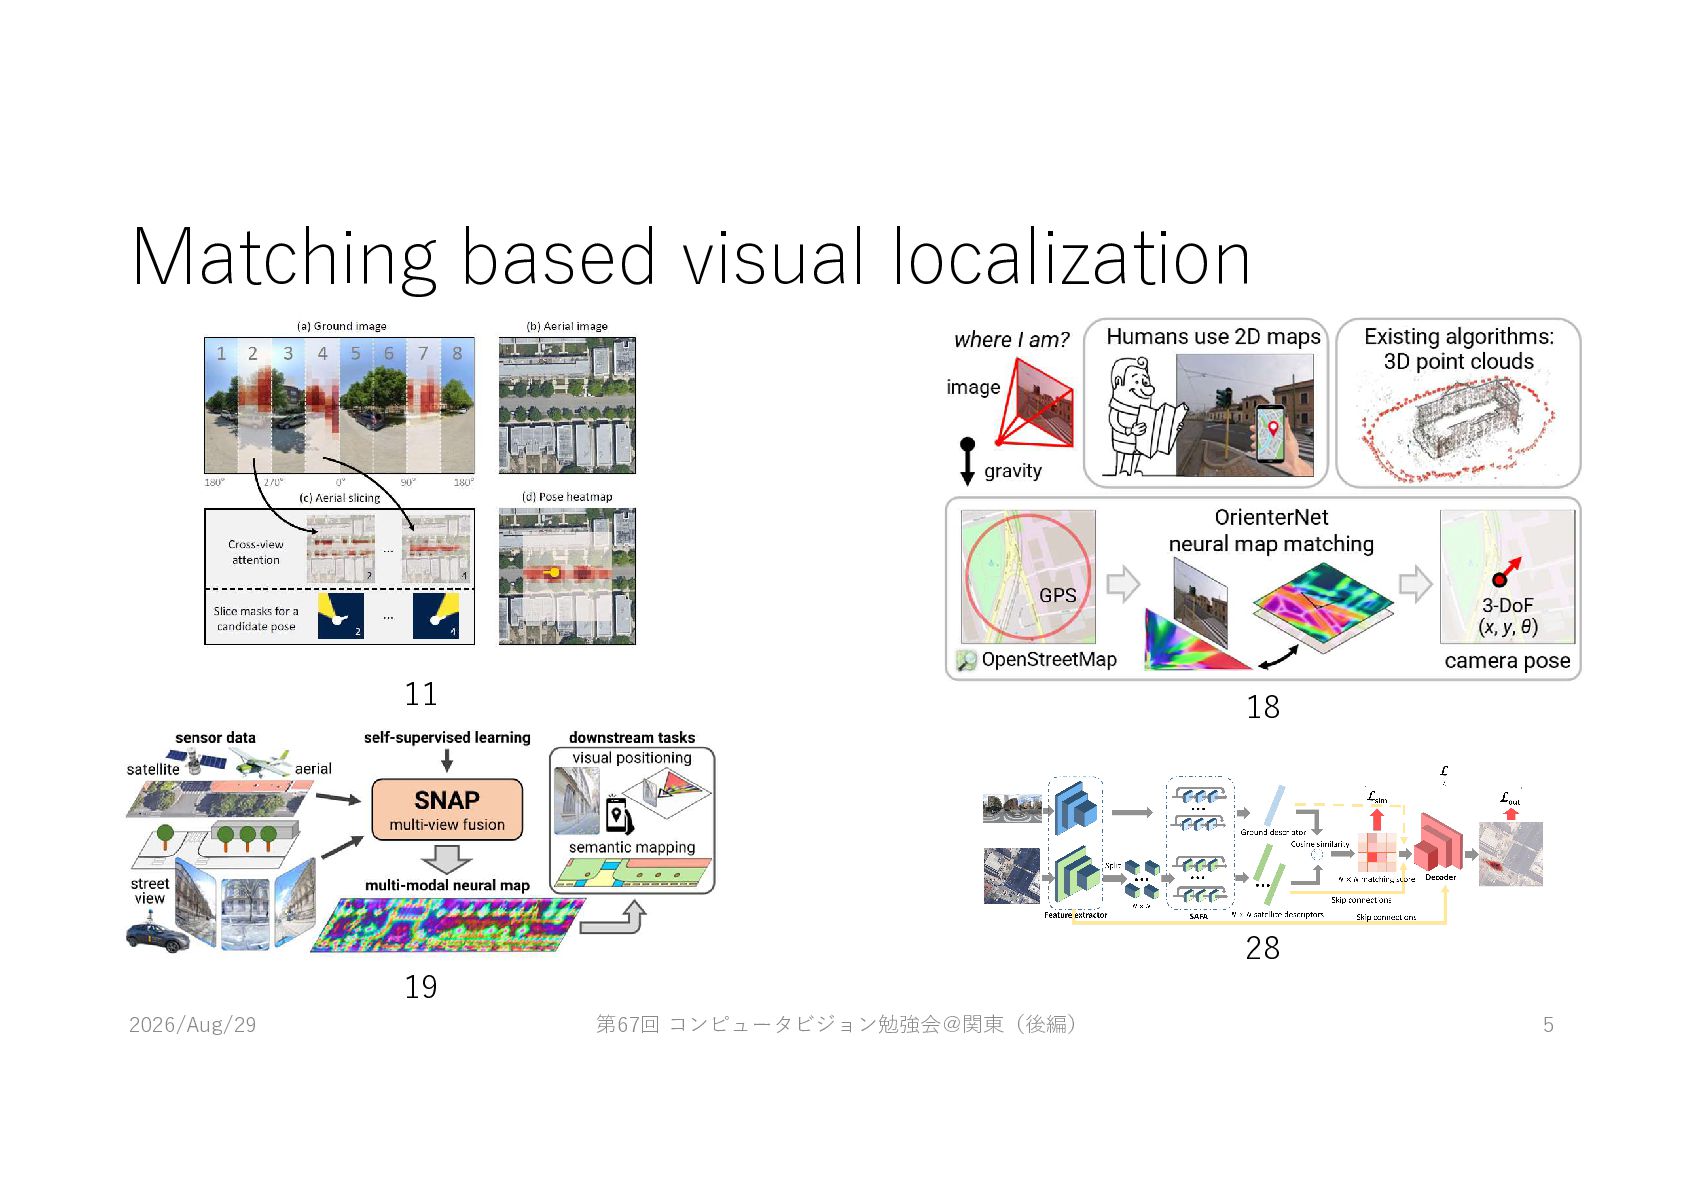
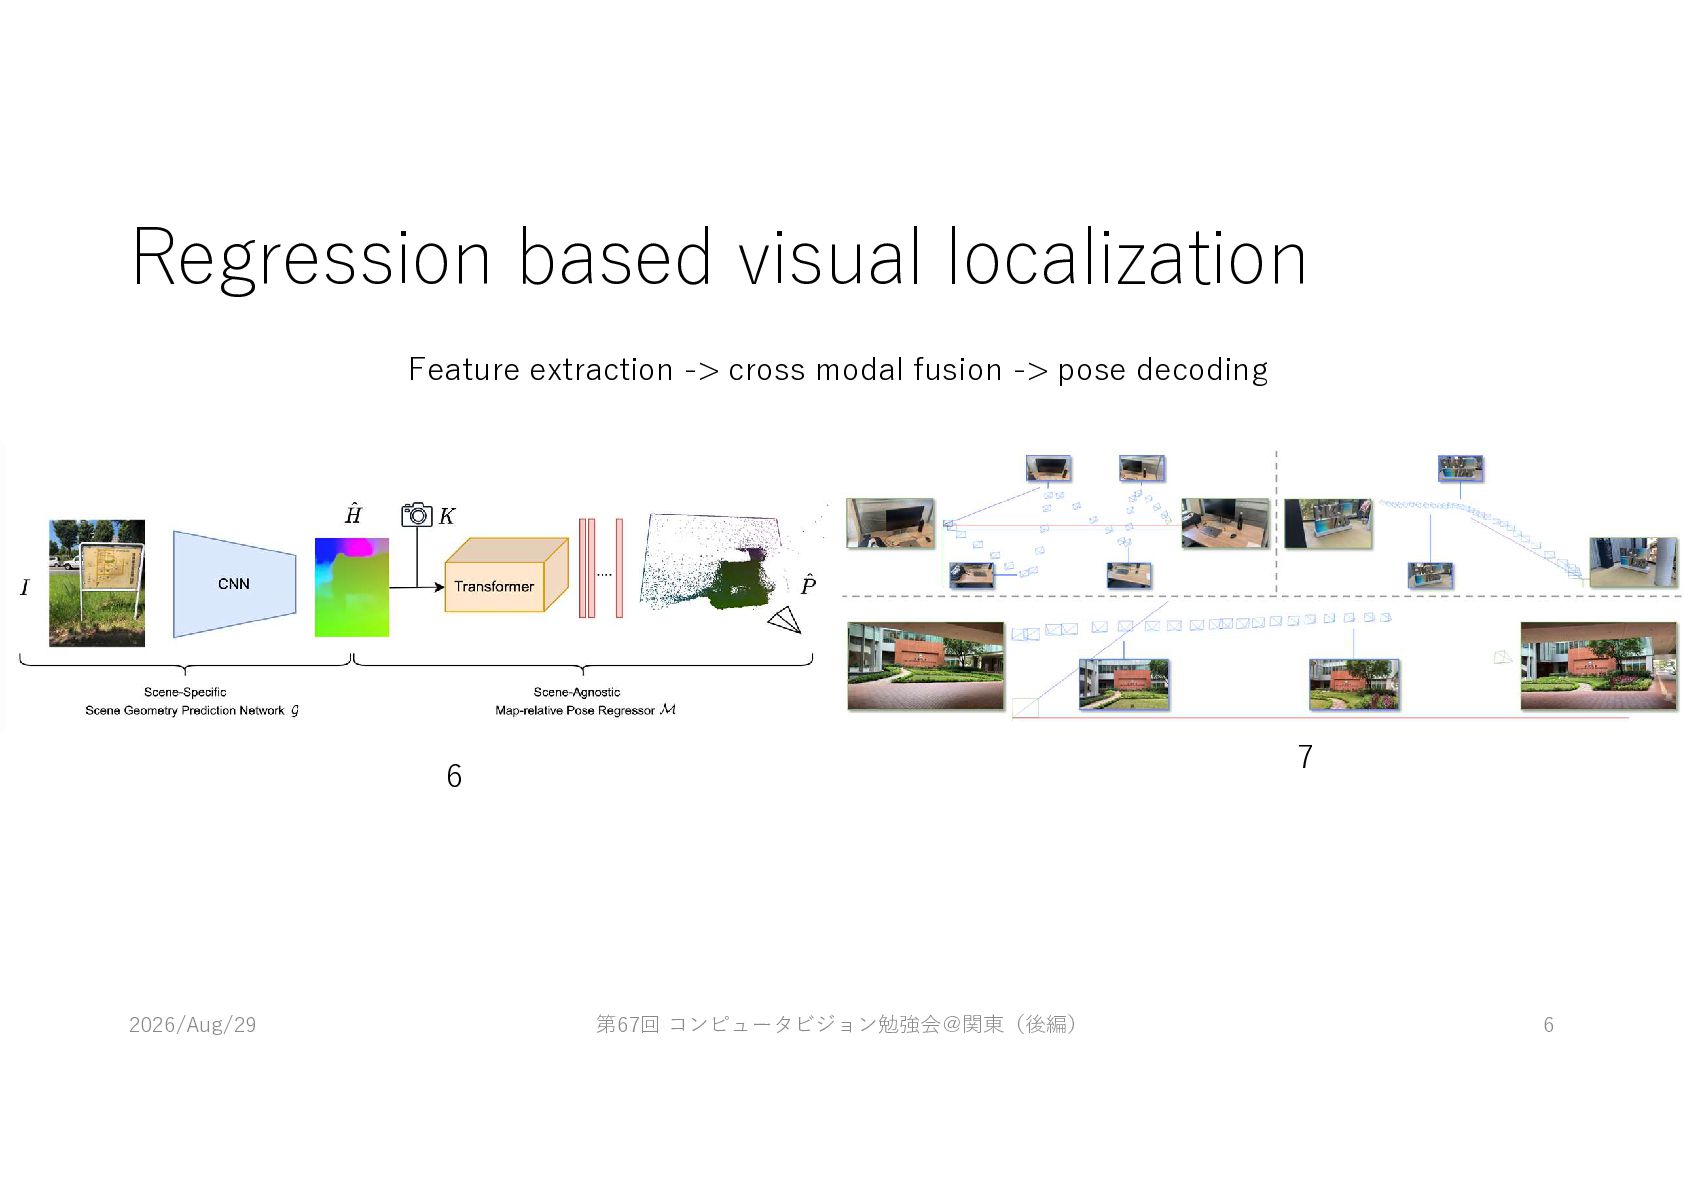
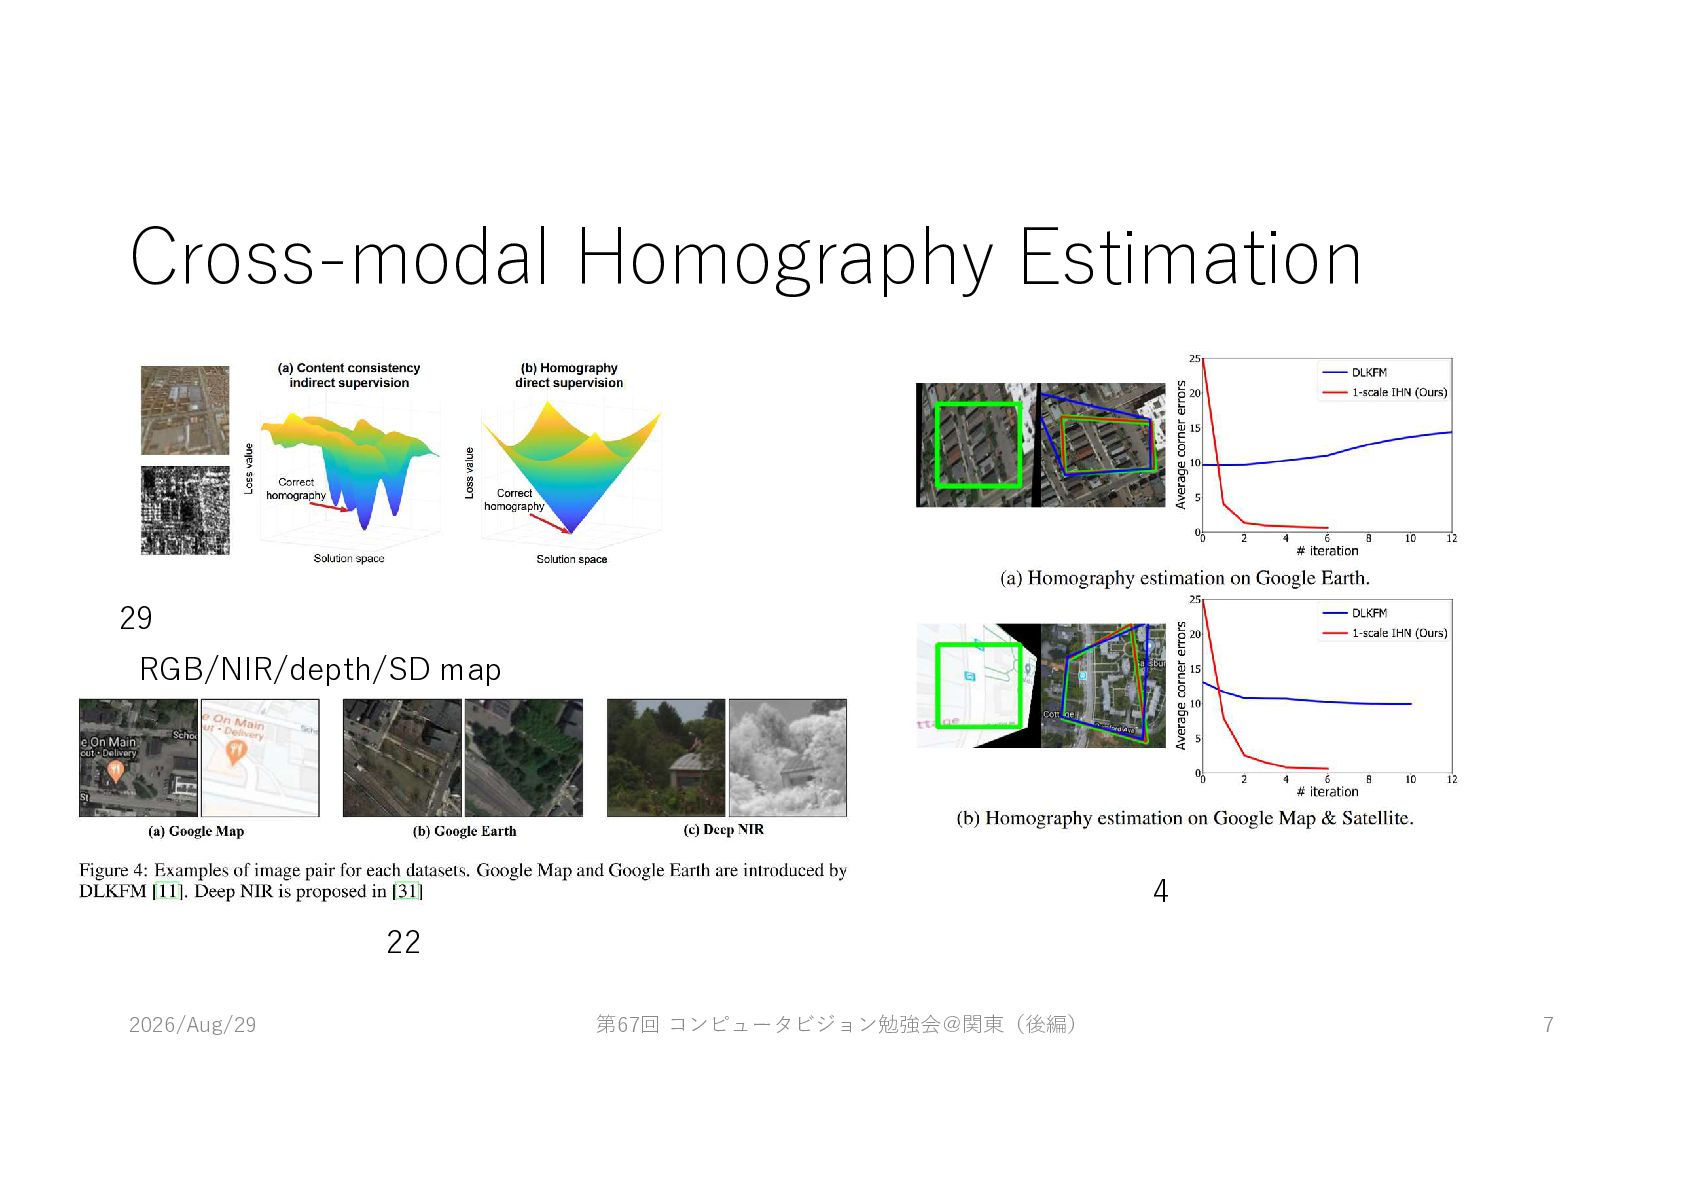
Shen. Iterative deep homography estimation. In Proceedings of the IEEE/CVF conference on computer vision and pattern recognition, pages 1879–1888, 2022 6: Shuai Chen, Tommaso Cavallari, Victor Adrian Prisacariu, and Eric Brachmann. Map-relative pose regression for visual re-localization. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, pages 20665–20674, 2024 7: Siyan Dong, Shuzhe Wang, Shaohui Liu, Lulu Cai, Qingnan Fan, Juho Kannala, and Yanchao Yang. Reloc3r: Largescale training of relative camera pose regression for generalizable, fast, and accurate visual localization. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), pages 16739–16752, 2025. 11: Ted Lentsch, Zimin Xia, Holger Caesar, and Julian FP Kooij. Slicematch: Geometry-guided aggregation for cross-view pose estimation. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, pages 17225–17234, 2023. 18: Paul-Edouard Sarlin, Daniel DeTone, Tsun-Yi Yang, Armen Avetisyan, Julian Straub, Tomasz Malisiewicz, Samuel Rota Bulo, Richard Newcombe, Peter Kontschieder, and Vasileios Balntas. Orienternet: Visual localization in 2d public maps with neural matching. In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, pages 21632–21642, 2023. 19: Paul-Edouard Sarlin, Eduard Trulls, Marc Pollefeys, Jan Hosang, and Simon Lynen. Snap: Self-supervised neural maps for visual positioning and semantic understanding. Advances in Neural Information Processing Systems, 36:7697–7729, 2023. 22: Sanghyeob Song, Jaihyun Lew, Hyemi Jang, and Sungroh Yoon. Unsupervised homography estimation on multimodal image pair via alternating optimization. Advances in Neural Information Processing Systems, 37:61306–61327, 2024 28: Zimin Xia, Olaf Booij, and Julian FP Kooij. Convolutional cross-view pose estimation. IEEE Transactions on Pattern Analysis and Machine Intelligence, 46(5):3813–3831, 2023 29: Junchen Yu, Si-Yuan Cao, Runmin Zhang, Chenghao Zhang, Zhu Yu, Shujie Chen, Bailin Yang, and Hui-Liang Shen. Sshnet: Unsupervised cross-modal homography estimation via problem reformulation and split optimization. In Proceedings of the Computer Vision and Pattern Recognition Conference, pages 16685–16694, 2025. 2026/Aug/29 第67回 コンピュータビジョン勉強会@関東(後編) 21


 tomoaki0705
 rmaruy
 junkashihara
 nagano
 arthur1
 butchi
 brainpadpr
 institutdelelevage
 hayashiyus884
 trycycle
 stillpedant
 cromwellryan
 techseoconnect
 chriscoyier
 portentint
 kimpetersen
 ivargrimstad
 raygrieselhuber
 skipperchong
 philnash
 baasie