Planning for Contact

Planning for Contact
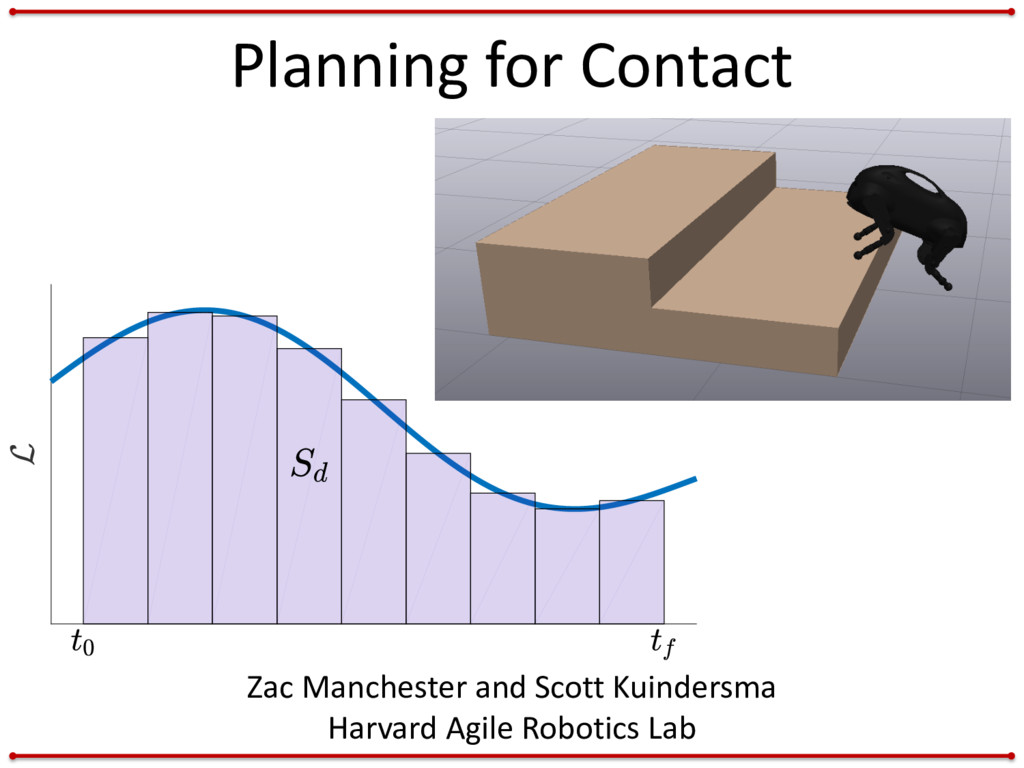
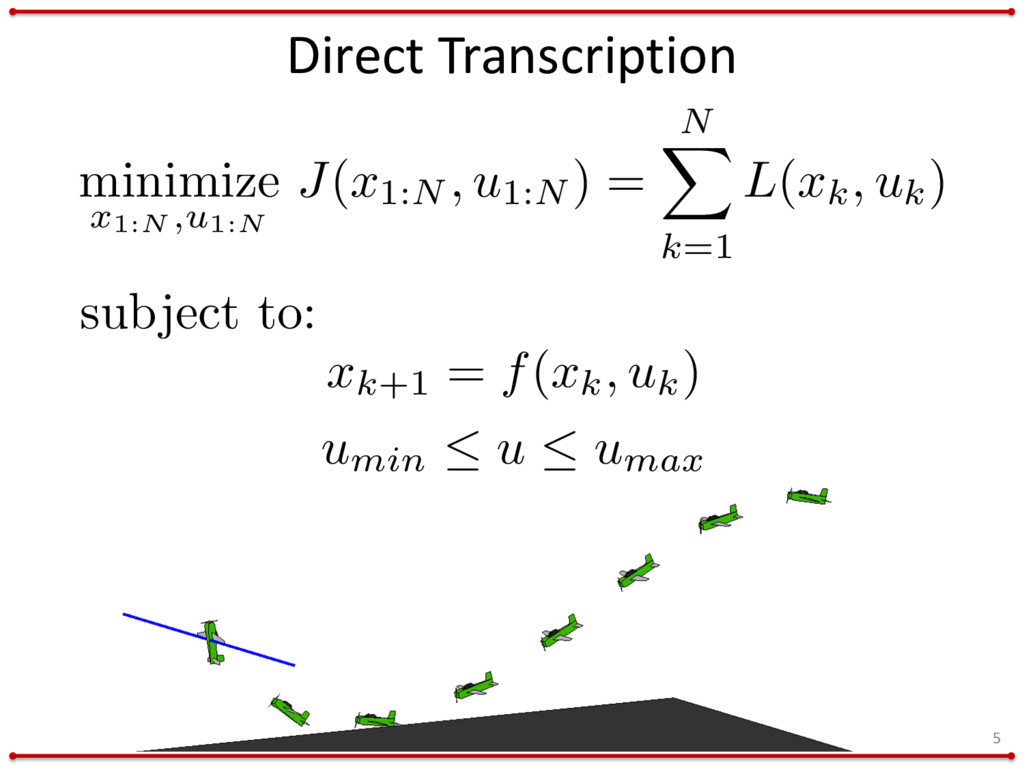
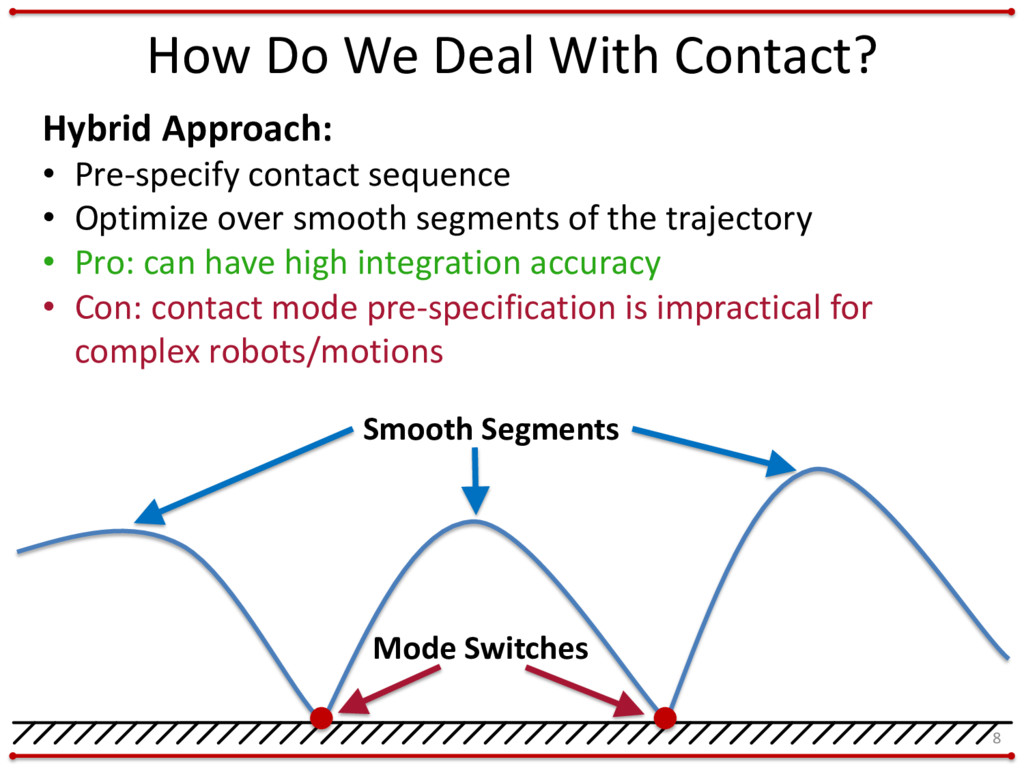
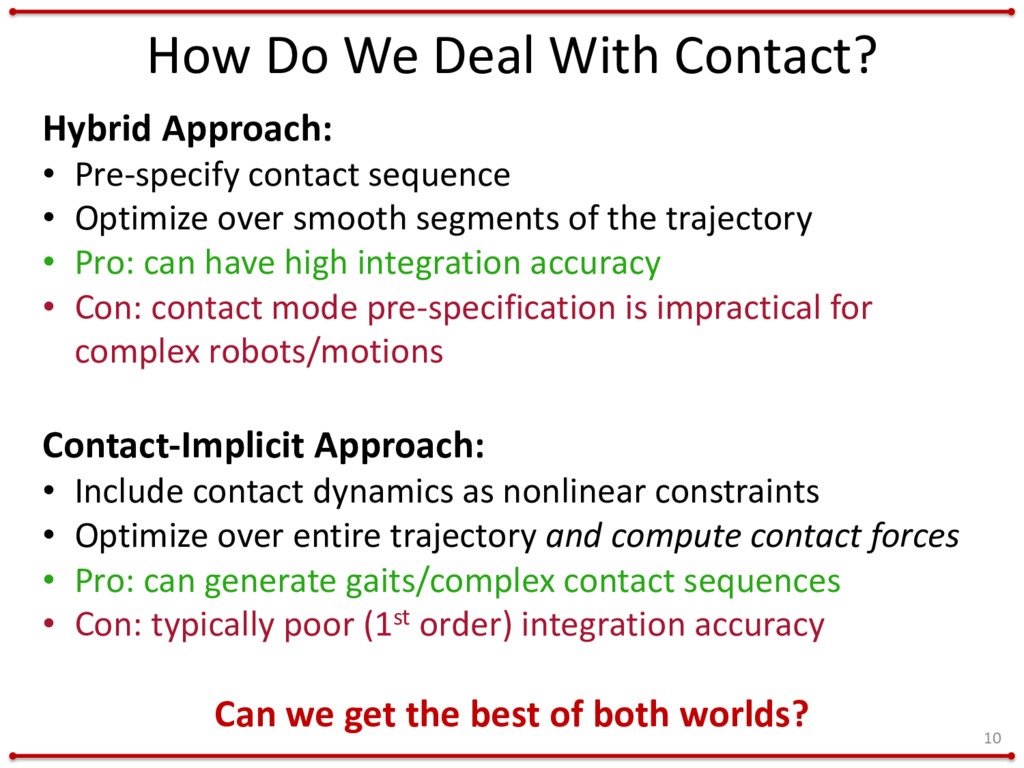
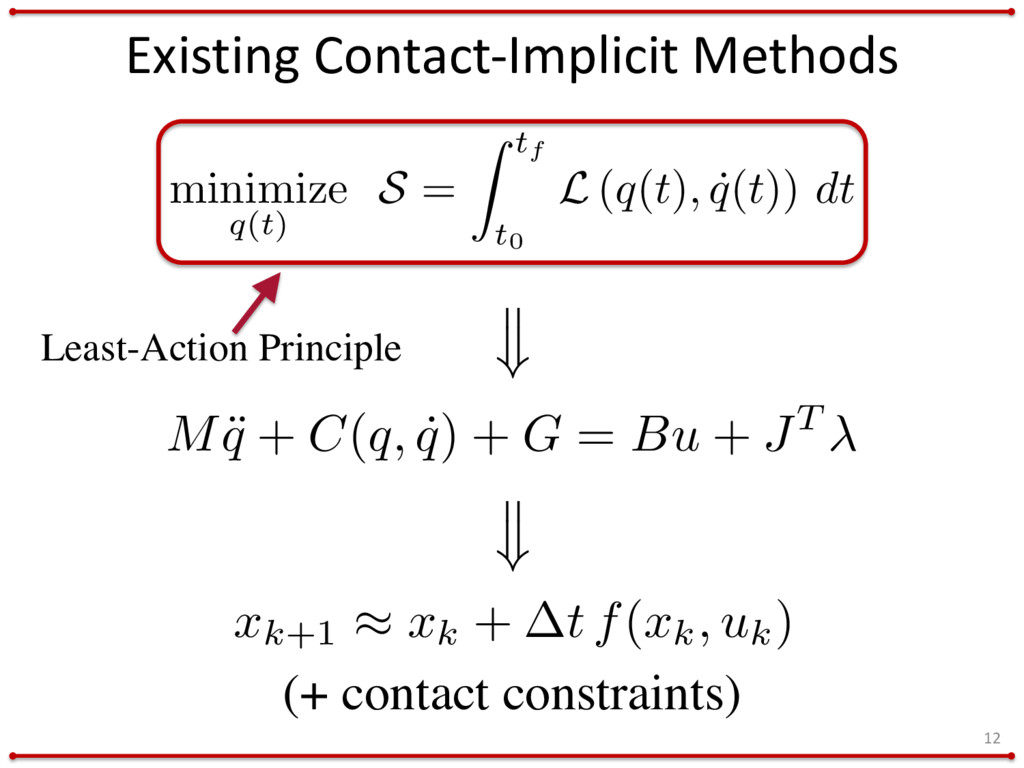
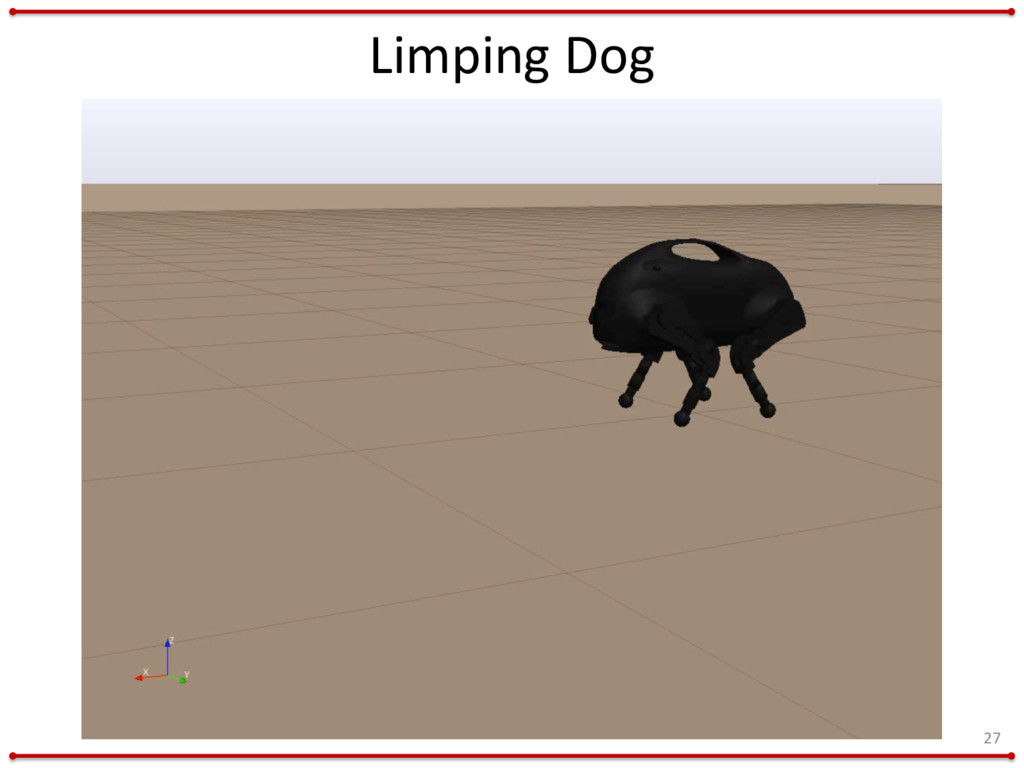
This is work presented at ISRR 2017 on motion planning for robots that experience contact.

Zac Manchester
November 12, 2017
This is work presented at ISRR 2017 on motion planning for robots that experience contact.
 zacmanchester
 yukako_nakano
 shunk031
 rikkabotan7
 institutdelelevage
 taira_tsuchiya
 pman0214
 yumulab
 uskimura
 erikaheidi
 helmedeiros
 dougneiner
 smashingmag
 hannesfritz
 ryanjones
 reverentgeek
 baasie
 tmiket
 shlominoach
 mkilby
 gurzu