Share
Embed
DyViR: Dynamic Virtual Reality Dataset for Aerial Threat Object Detection
Presentation at the SPIE Defense + Commercial Sensing Conference
Gregory Ditzler
June 07, 2023
Transcript
15 slides
-
Presented By: Gregory Ditzler(1,2) (1)Department of Electrical & Computer Engineering
(2)Machine Artificial Intelligence and Virtual Reality Center (MAVRC) Rowan University Glassboro, NJ DyViR: Dynamic Virtual Reality Dataset for Aerial Threat Object Detection Garrett Williams, George D. Lecakes Jr., Amanda Almon, Nikolas Koutsoubis, Kyle Naddeo, Thomas Kiel, Gregory Ditzler, and Nidhal C. Bouaynaya -
Outline • UAV Threat/Object Detection using ML • Motivating Data
Augmentation using Synthetic Data • Real-Time Rendering Technology • What is DyViR and what does it produce? ◦ YOLOv7-tiny Training and Validation ◦ Results from YOLOv7-tiny ML models • Conclusions and Future Directions -
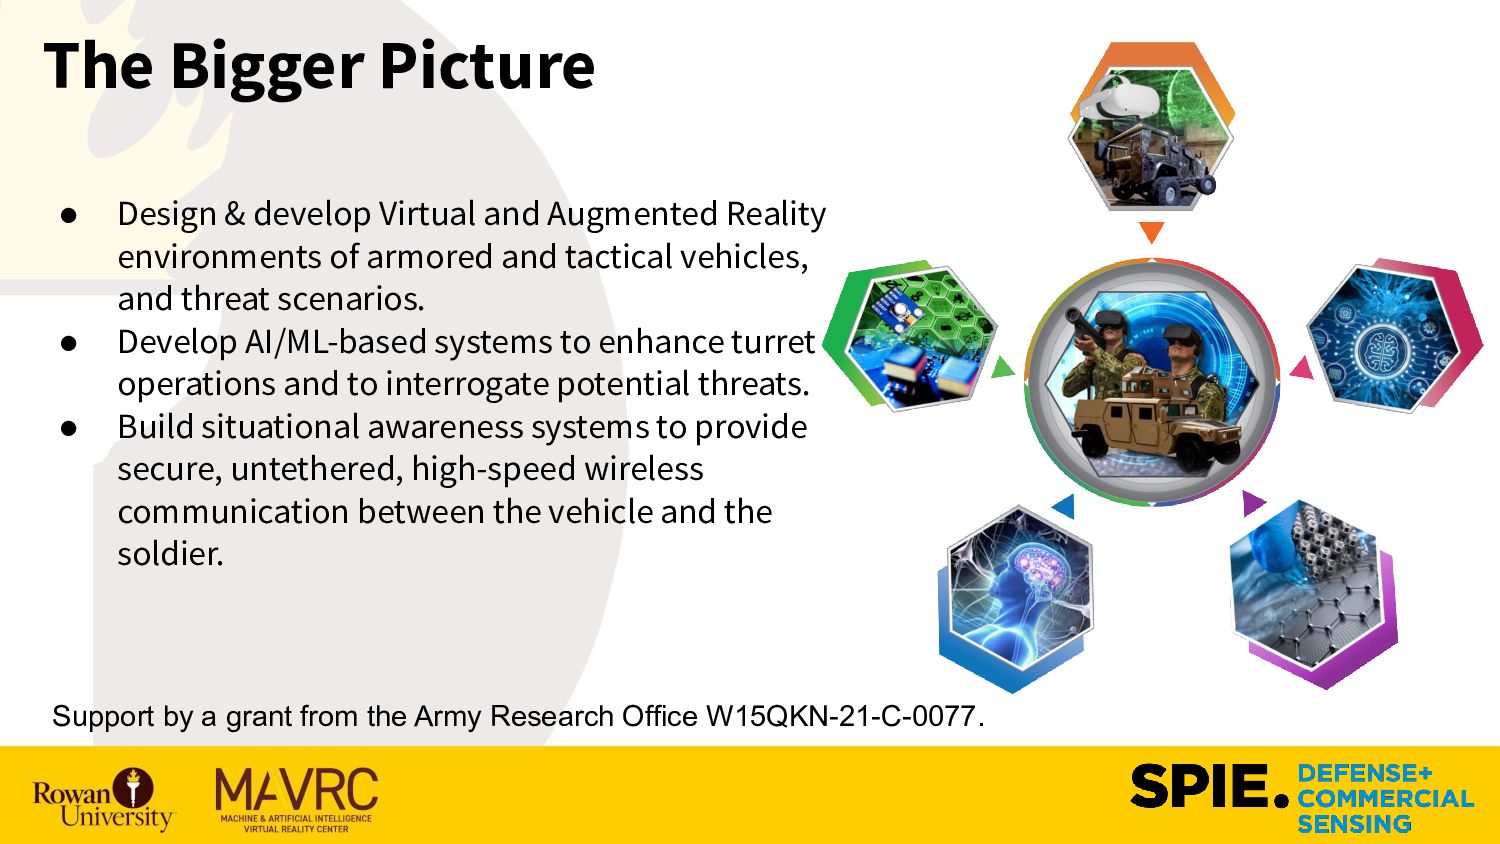
The Bigger Picture • Design & develop Virtual and Augmented
Reality environments of armored and tactical vehicles, and threat scenarios. • Develop AI/ML-based systems to enhance turret operations and to interrogate potential threats. • Build situational awareness systems to provide secure, untethered, high-speed wireless communication between the vehicle and the soldier. Support by a grant from the Army Research Office W15QKN-21-C-0077. -
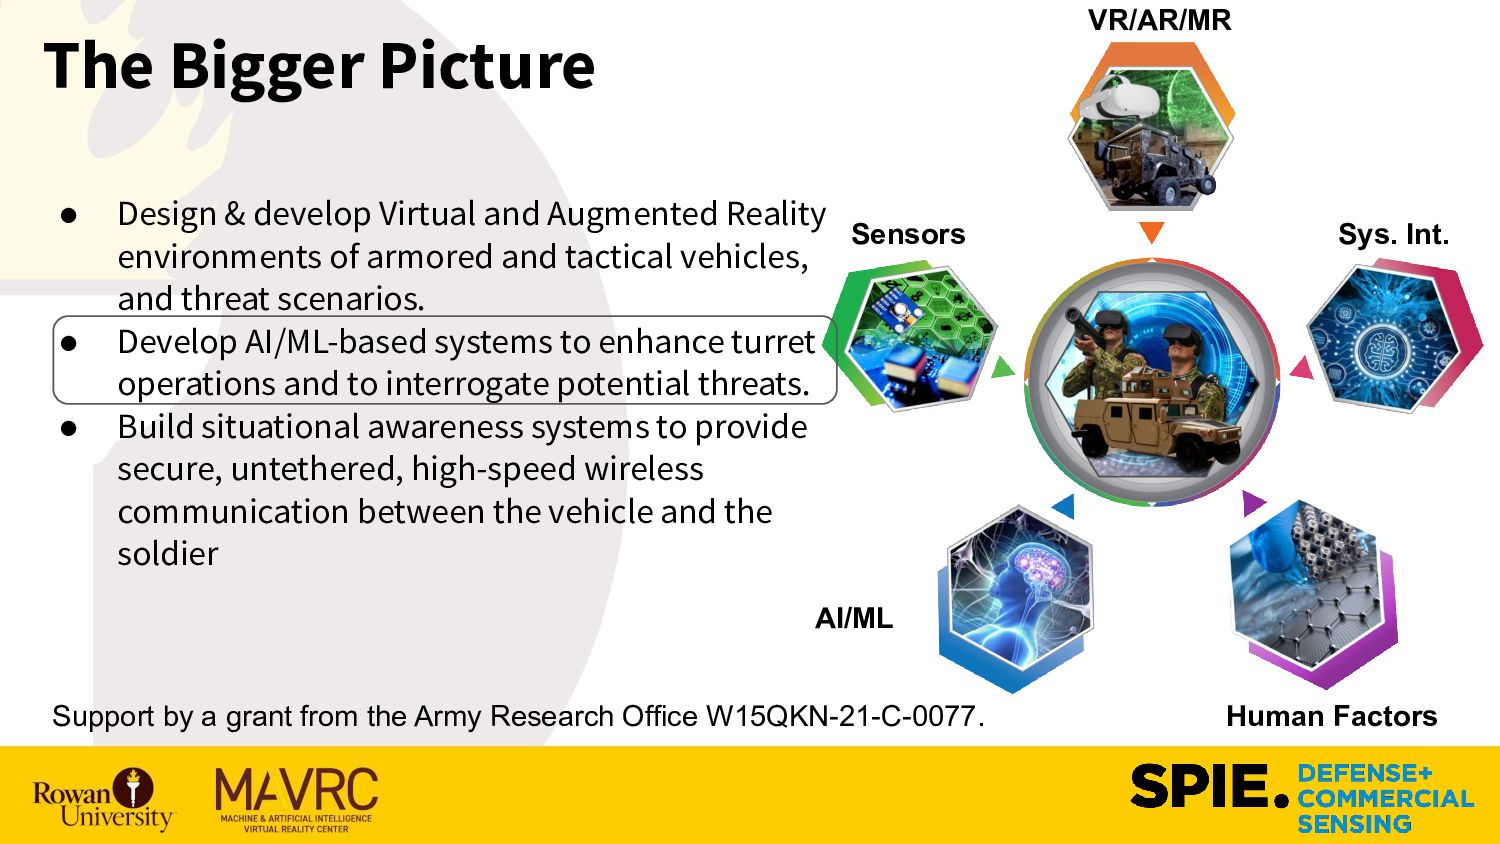
The Bigger Picture • Design & develop Virtual and Augmented
Reality environments of armored and tactical vehicles, and threat scenarios. • Develop AI/ML-based systems to enhance turret operations and to interrogate potential threats. • Build situational awareness systems to provide secure, untethered, high-speed wireless communication between the vehicle and the soldier Support by a grant from the Army Research Office W15QKN-21-C-0077. Sensors Human Factors VR/AR/MR AI/ML Sys. Int. -
UAV Object Detection using ML • Unmanned Aerial Vehicles (UAVs)
pose a major threat on the modern combat landscape ◦ These objects tend to be small (e.g., contained on a small number of pixels), and ◦ There are limited datasets available to learn an object detector. ▪ Number of samples ▪ Types of UAVs ▪ Biomes where data are collected ▪ Etc. • Machine Learning (ML) is a potential solution in identifying and classifying friendly and hostile UAVs in large swarms; however, limited data will limit the performance of any ML model. -
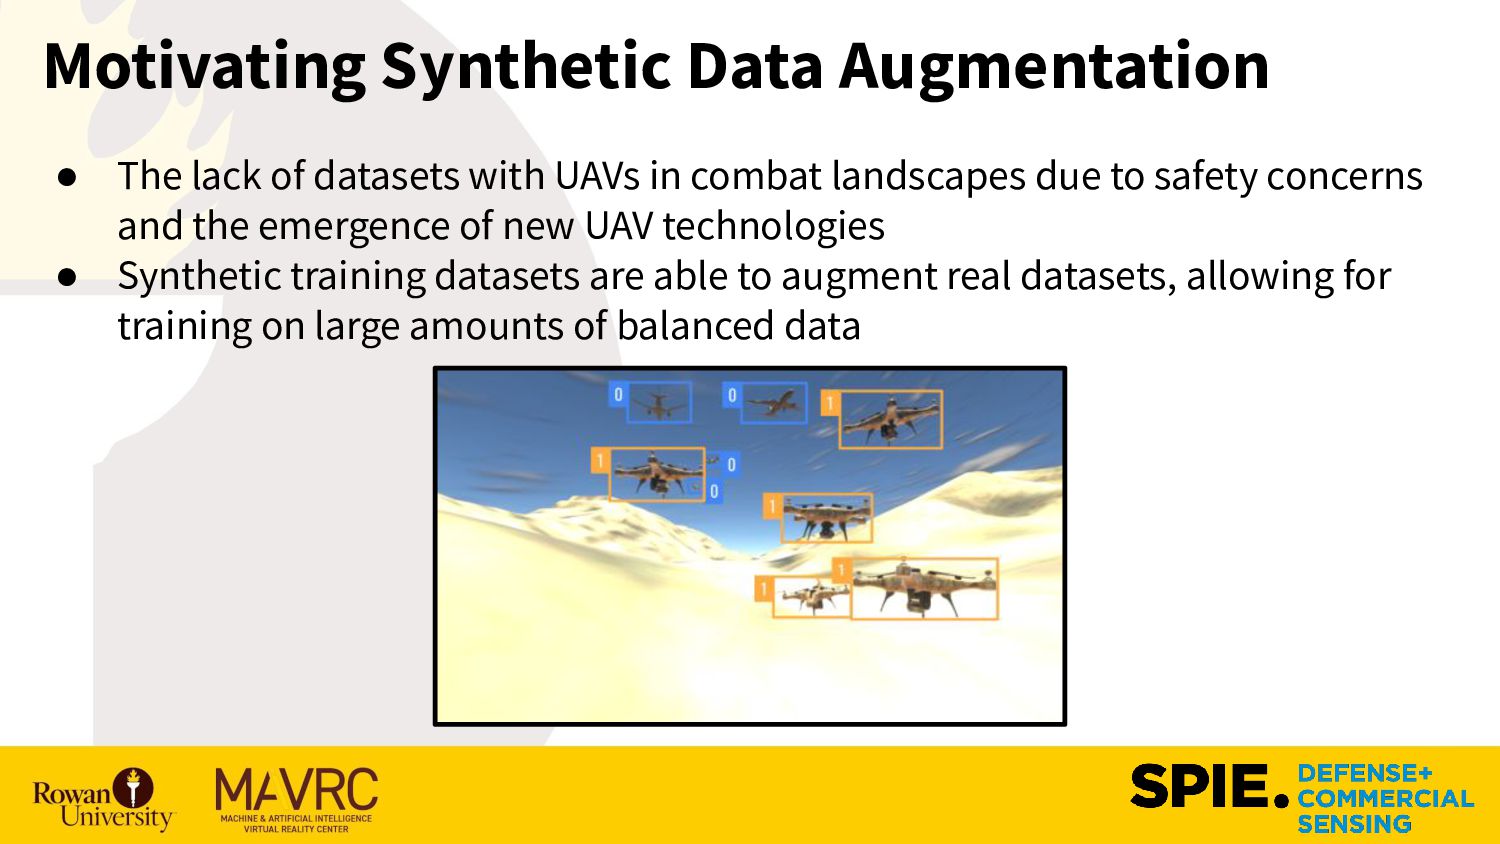
Motivating Synthetic Data Augmentation • The lack of datasets with
UAVs in combat landscapes due to safety concerns and the emergence of new UAV technologies • Synthetic training datasets are able to augment real datasets, allowing for training on large amounts of balanced data -
Real-Time Rendering Technology • Advancements in computer graphics allow for
the realistic renderings of 3D digital environments produced in real-time (30 frames per second +) • Imagery of custom 3D assets in a simulated 3D environment is created by software such as the Unity Real-Time Development Platform (Unity) ◦ The developer of the datasets are no longer limited by the biome, types of drones, etc. ◦ This allows for users to develop more diverse datasets • Real-time rendering allows for the rapid production of synthetic datasets -
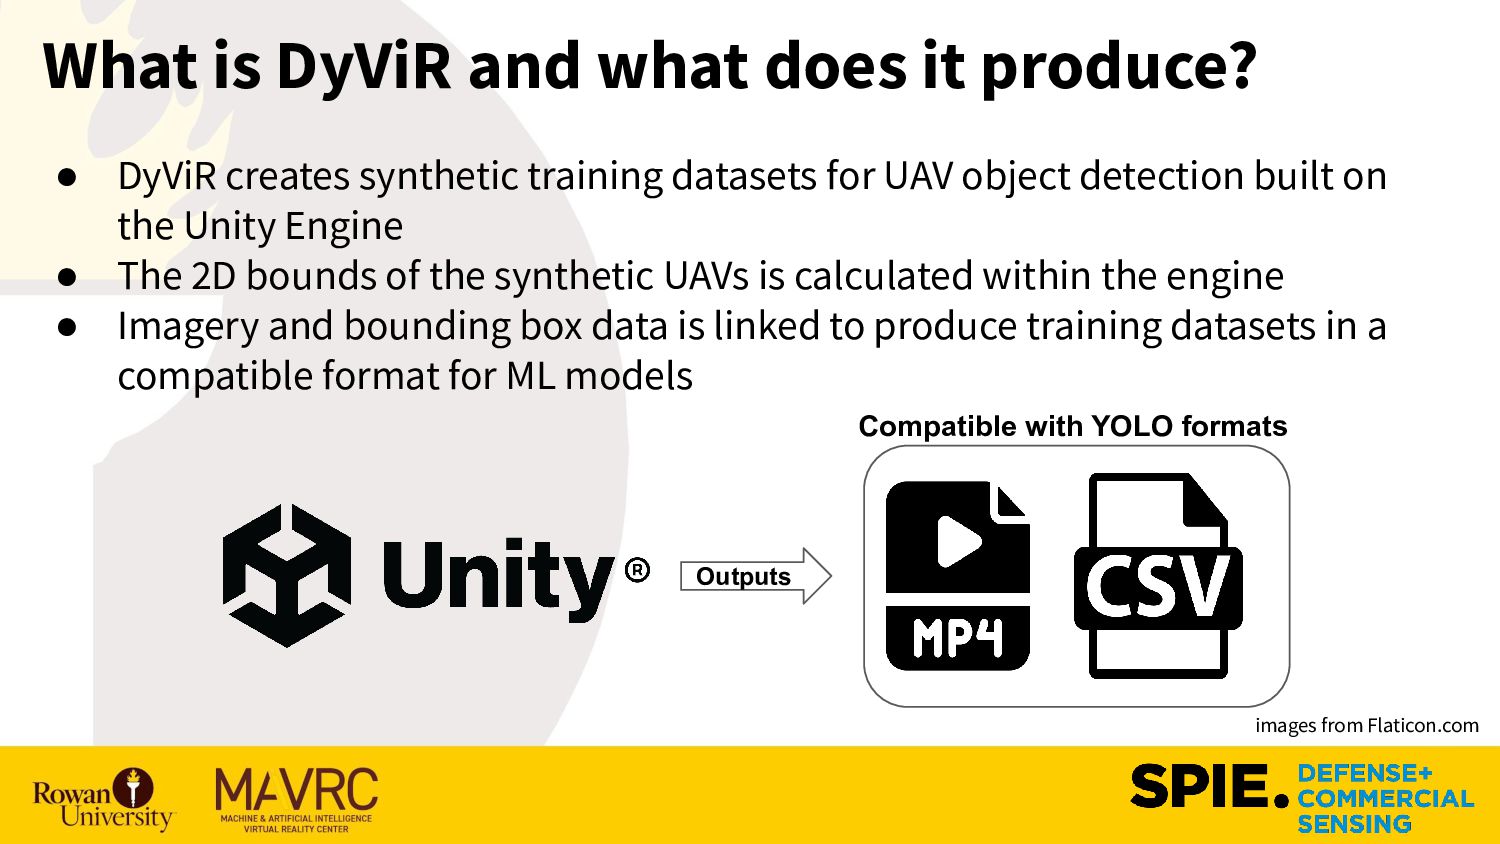
What is DyViR and what does it produce? • DyViR
creates synthetic training datasets for UAV object detection built on the Unity Engine • The 2D bounds of the synthetic UAVs is calculated within the engine • Imagery and bounding box data is linked to produce training datasets in a compatible format for ML models Outputs images from Flaticon.com Compatible with YOLO formats -
YOLOv7-tiny Training and Validation • The You Only Look Once
(YOLO) model is designed for object detection • The YOLOv7-tiny model is a lightweight variant suitable for deployment on edge devices ◦ YOLOv7-tiny classifies objects and places a bounding box identifying the extents of the object • The Mean Average Precision (mAP) score is a metric for determine the performance of object detection -
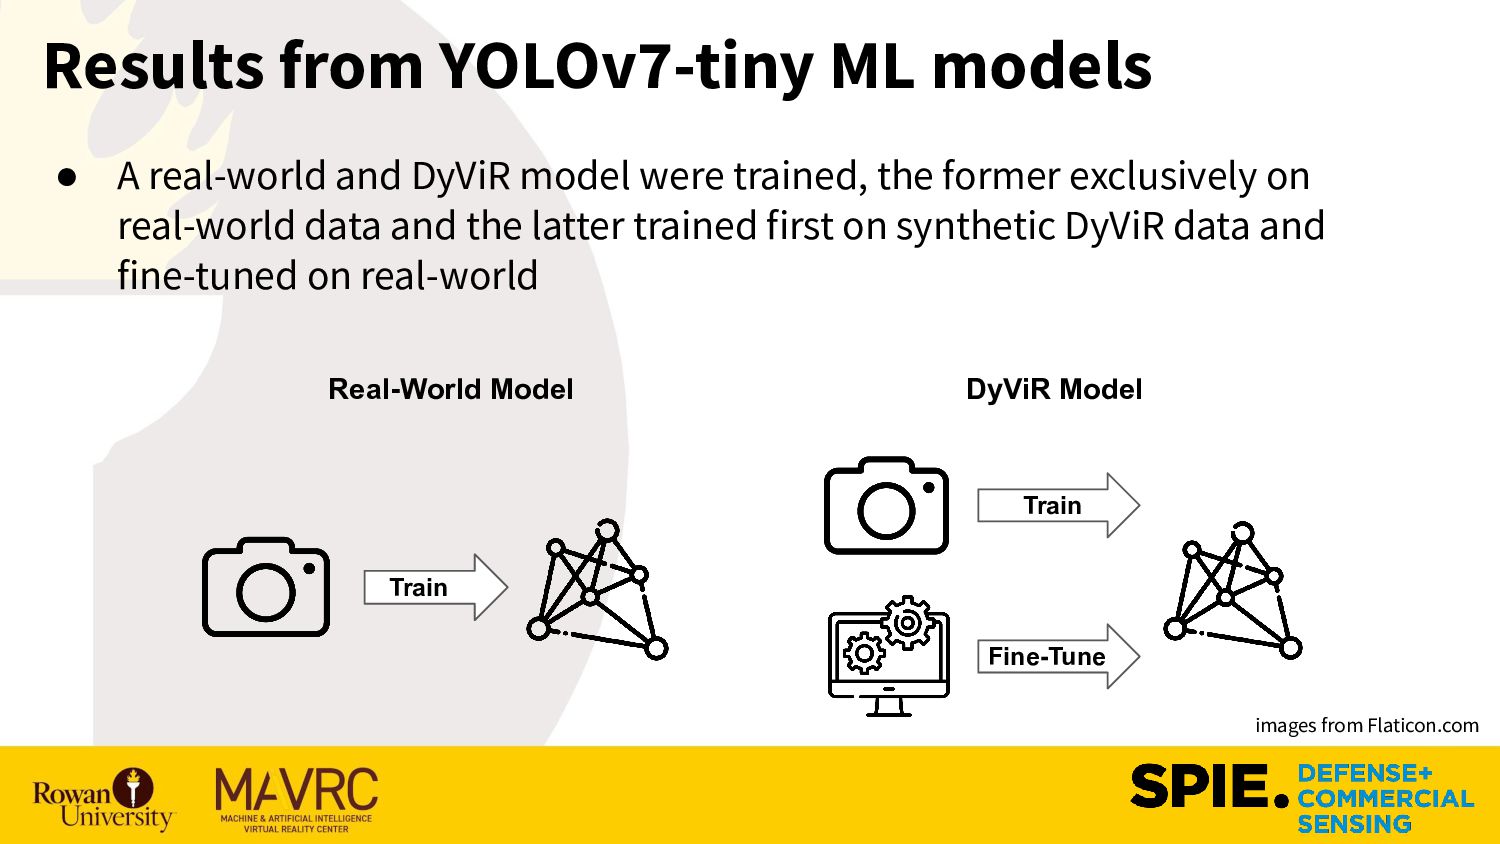
• A real-world and DyViR model were trained, the former
exclusively on real-world data and the latter trained first on synthetic DyViR data and fine-tuned on real-world Results from YOLOv7-tiny ML models Real-World Model images from Flaticon.com DyViR Model Train Fine-Tune Train -
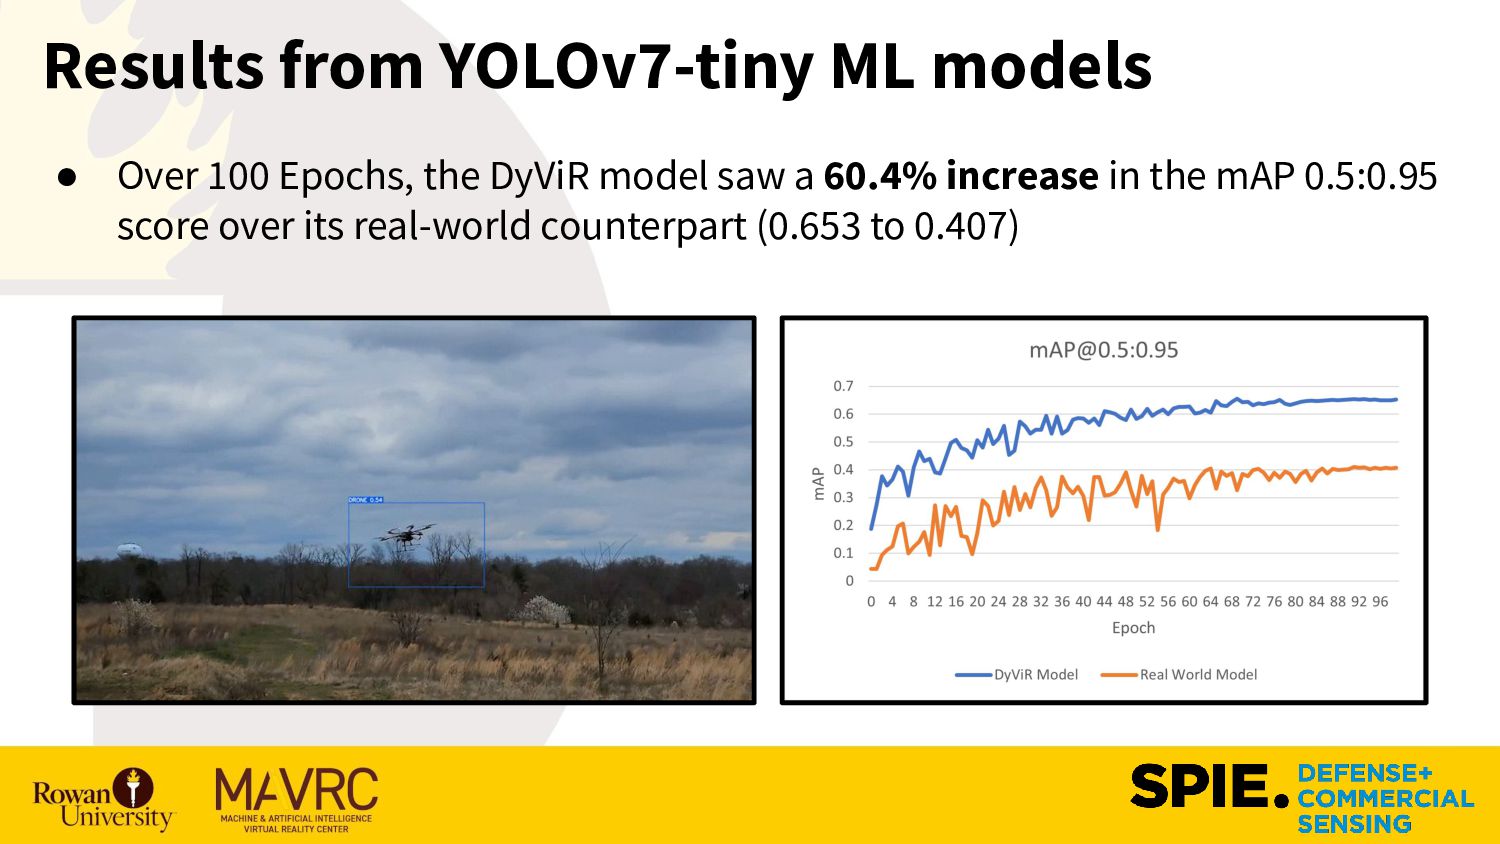
• Over 100 Epochs, the DyViR model saw a 60.4%
increase in the mAP 0.5:0.95 score over its real-world counterpart (0.653 to 0.407) Results from YOLOv7-tiny ML models -
• Access to real-world data to build a robust and
trustworthy machine learning model can be challenging when real-world data are scarce ◦ Real-world data can be challenging or near impossible to collect ◦ Collecting data that covers all p(x) can be challenging regarding ▪ Different biomes, UAVs, weather, etc. • DyViR allows for rapid development of new datasets for aerial object detection. • Future Work: DyViR intends to produce datasets that have more realistic flight patterns, allowing for object detection-based on temporal changes ◦ Develop software to superimpose VR drones over real-scenes ◦ Investigate curriculum learning methods to boost performance Conclusion -
Thank you! Questions? This work was supported by grants from
the Army Research Office W15QKN-21-C-0077, and National Science Foundation CAREER #1943552. Any opinions, findings, and conclusions or recommendations expressed in this material are those of the authors and do not necessarily reflect the sponsors' views. Data https://github.com/RowanMAVRC/DyViR-For-Unity-SPIE-2023