Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
ミニ四駆チキンレース参戦記(敗)
Search
Google Homer
June 21, 2019
Technology
1.3k
1
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
ミニ四駆チキンレース参戦記(敗)
Google Homer
June 21, 2019
More Decks by Google Homer
See All by Google Homer
意外とお手軽Donkey AI Car(ありがとうIoTLT)
googlehomer
0
780
ゆるふわマシンラーニング×ゆるメカトロでDonkey AI Car
googlehomer
0
340
私Servoですけど、ぐるぐる回りますが 何か ?!
googlehomer
0
430
The latest information on obniz for all of IoTLT’s
googlehomer
1
350
IoTLT vol.58@SoftBank IoTLT木曜サスペンス劇場
googlehomer
0
830
micro:bitはobnizの夢をみるか?
googlehomer
1
880
Invitation for RPA next stage @UiPathFriendsライトニングトークナイト2019
googlehomer
0
130
M5StickC Block Programming UiFLOW @ ビジュアルプログラミング交流会
googlehomer
1
750
Smart Speaker & IoT @東北TECH道場 八戸道場
googlehomer
0
160
Other Decks in Technology
See All in Technology
【データ横丁主催】AI エージェント時代のTranslytical Data Platform
shisyu_gaku
0
300
クラウドエージェントの先駆け Devin。今も最先端を走る、他との違い
kinopeee
0
400
DevelopersIO 2026 Tokyo 現時点の衛星通信サービスの現状を整理してみる
maroon1st
0
310
AI駆動開発におけるハーネスエンジニアリングの勘所
tsukuboshi
1
780
How we choose session proposals
kawaguti
PRO
0
170
1週間、Opus封印でお願いします
kintotechdev
0
170
Maestro MCPとClaude Code Skillsによる自律的なE2Eテスト支援
asmz
0
100
Metadata - Section 2: Simple Metadata & Meta Tags
mohab1
0
140
Teaching Python with three kinds of AI
reuven
0
120
AWS Continuum for Penetration Testing に Deep Dive してみる
asanoharuki
1
1.4k
Claude for Google Workspaces ポン出し/claude-for-google-workspace-slide-conversion
emiki
0
13k
あなたのDartコードは丸見えかもしれない ~reFlutterで暴くFlutterアプリの中身と多層防御~
zozotech
PRO
0
170
Featured
See All Featured
Exploring the Power of Turbo Streams & Action Cable | RailsConf2023
kevinliebholz
37
6.6k
The AI Revolution Will Not Be Monopolized: How open-source beats economies of scale, even for LLMs
inesmontani
PRO
3
3.8k
Breaking role norms: Why Content Design is so much more than writing copy - Taylor Woolridge
uxyall
1
460
Tell your own story through comics
letsgokoyo
1
1.1k
Reality Check: Gamification 10 Years Later
codingconduct
0
2.3k
Abbi's Birthday
coloredviolet
4
10k
State of Search Keynote: SEO is Dead Long Live SEO
ryanjones
0
330
Marketing to machines
jonoalderson
1
5.9k
Design of three-dimensional binary manipulators for pick-and-place task avoiding obstacles (IECON2024)
konakalab
0
630
Product Roadmaps are Hard
iamctodd
55
13k
Speed Design
sergeychernyshev
33
2.2k
Helping Users Find Their Own Way: Creating Modern Search Experiences
danielanewman
31
3.4k
Transcript
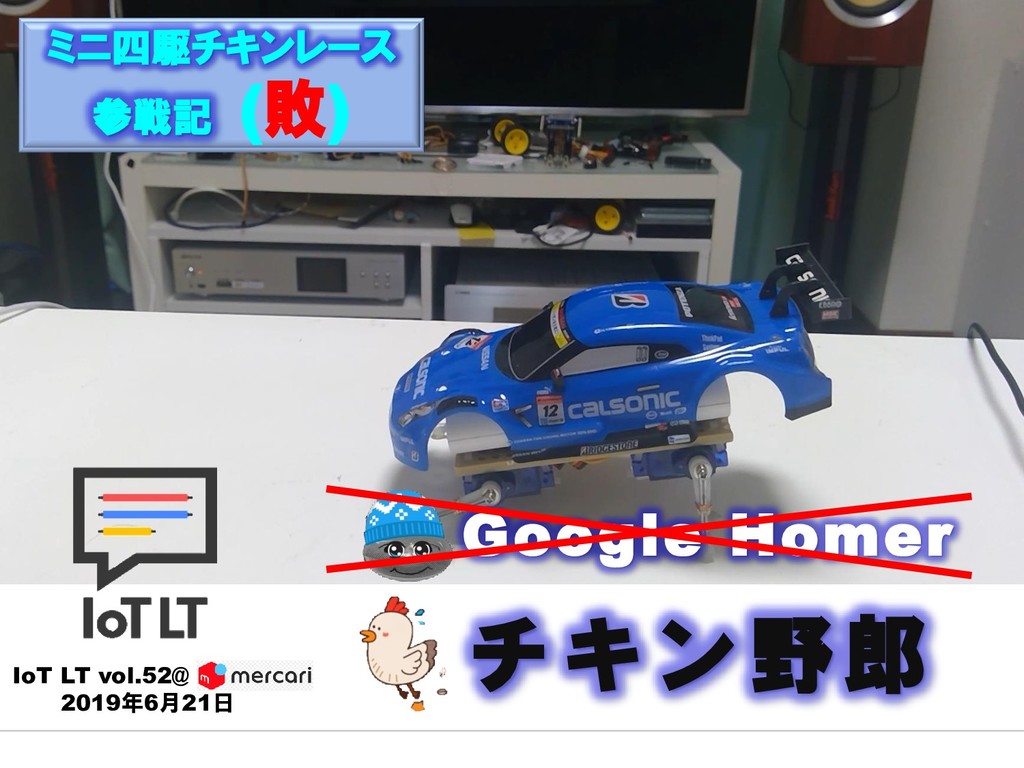
Google Homer IoT LT vol.52@ 2019年6月21日 チキン野郎 ミニ四駆チキンレース 参戦記 (敗)
こだわったこと ミニ四駆 速く、カッコよく !
小型化 : obniz 大貢献 距離センサー、DC Motor直挿し
いざ 爆走
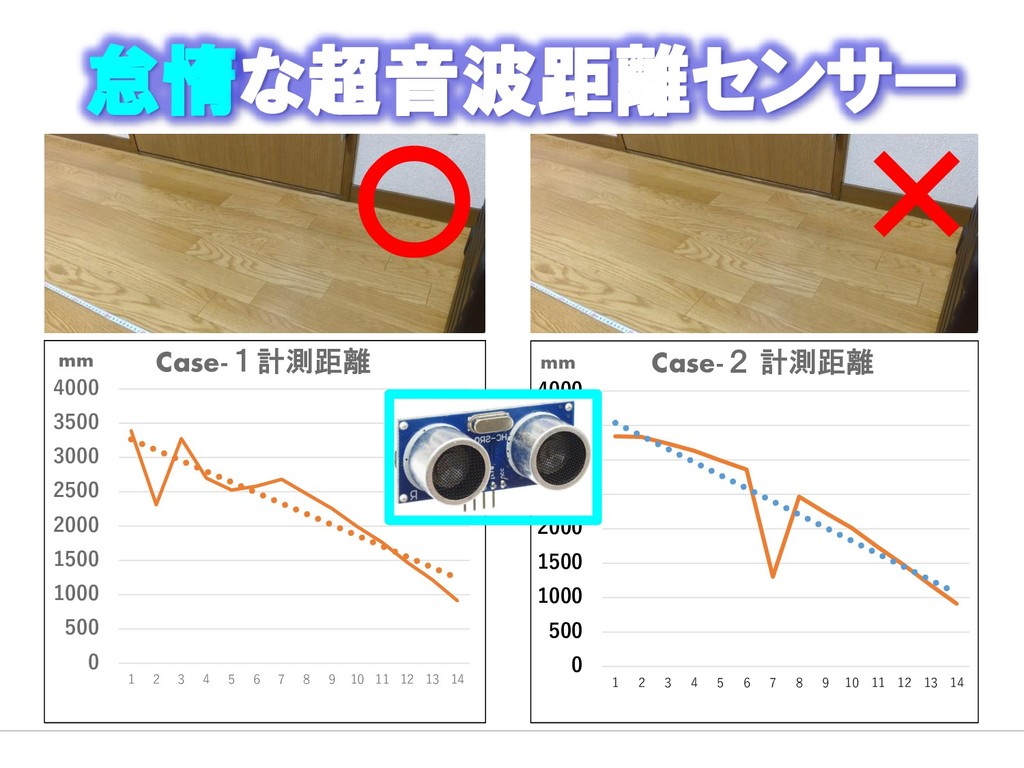
0 500 1000 1500 2000 2500 3000 3500 4000 1
2 3 4 5 6 7 8 9 10 11 12 13 14 mm Case-1計測距離 〇 怠惰な超音波距離センサー 0 500 1000 1500 2000 2500 3000 3500 4000 1 2 3 4 5 6 7 8 9 10 11 12 13 14 Case-2 計測距離 mm ×
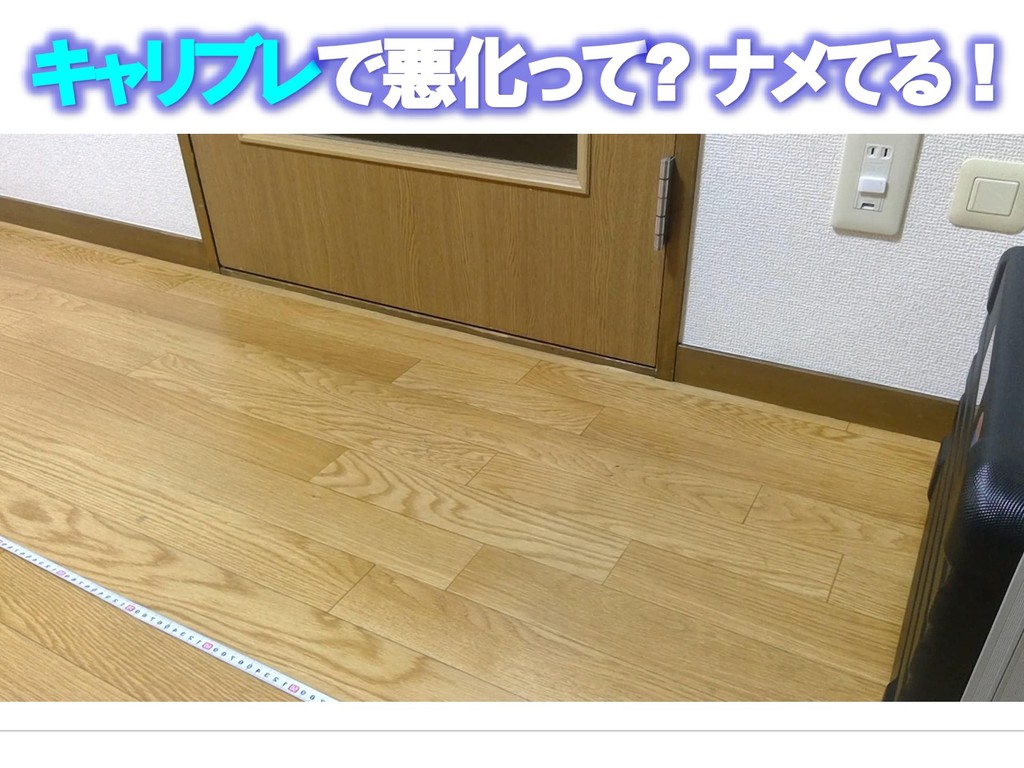
キャリブレで悪化って? ナメてる !
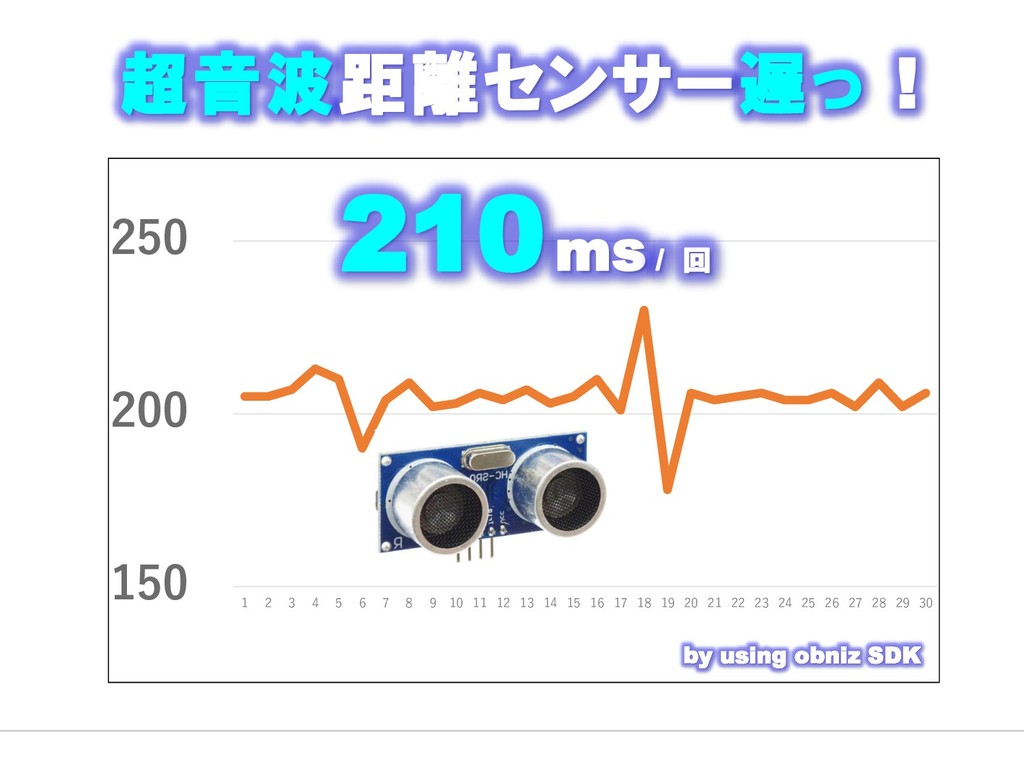
150 200 250 1 2 3 4 5 6 7
8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 超音波距離センサー遅っ ! 210ms / 回 by using obniz SDK
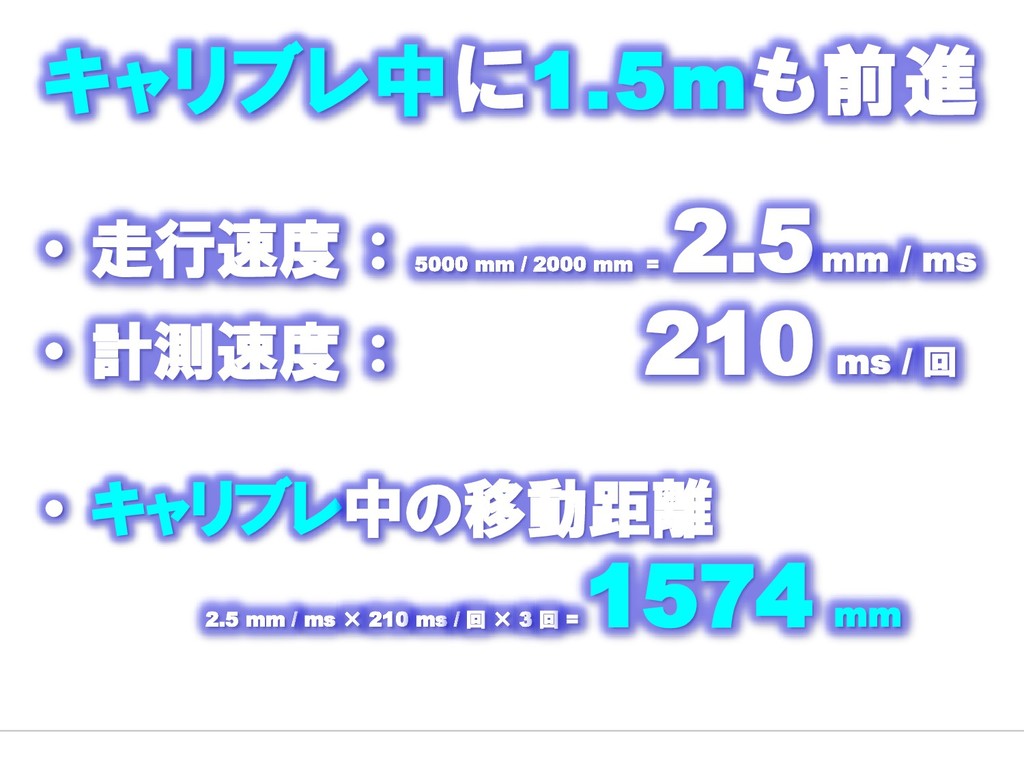
・ 走行速度 : 5000 mm / 2000 mm = 2.5mm
/ ms ・ 計測速度 : 210 ms / 回 ・ キャリブレ中の移動距離 2.5 mm / ms × 210 ms / 回 × 3 回 = 1574 mm キャリブレ中に1.5mも前進
フィードバック 制御不可 作戦変更へ
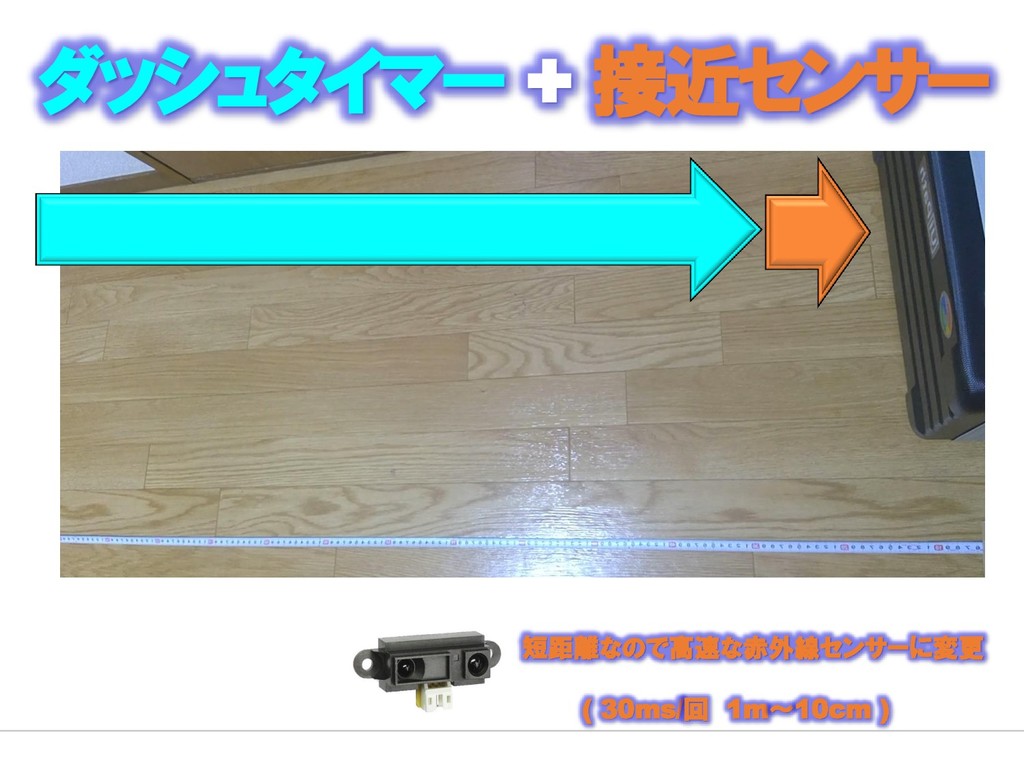
ダッシュタイマー + 接近センサー 短距離なので高速な赤外線センサーに変更 ( 30ms/回 1m~10cm )
追い込 み開始
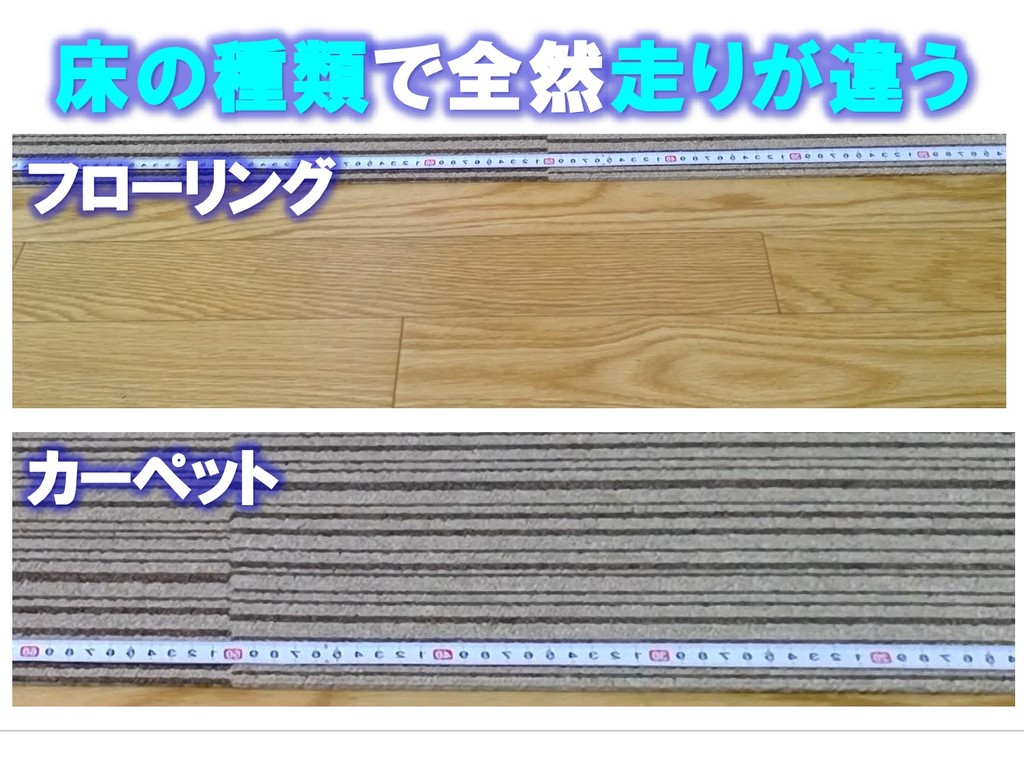
フローリング カーペット 床の種類で全然走りが違う
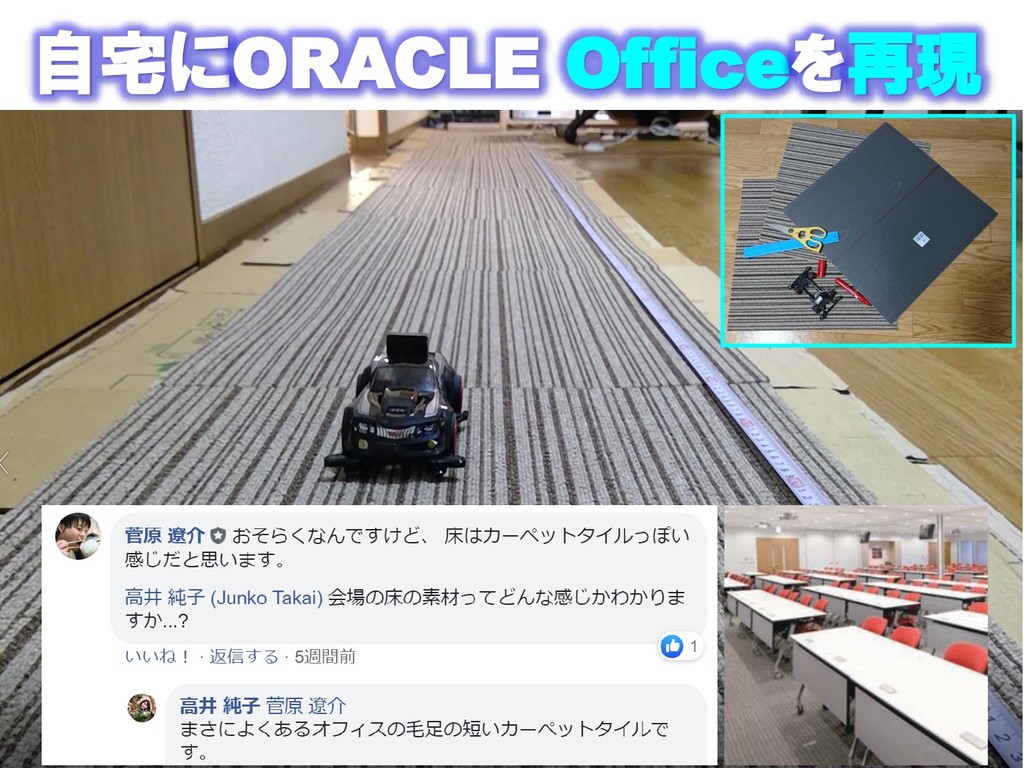
自宅にORACLE Officeを再現
90g 増 (単四×4本) で速度20%低下 1100mm/500ms = 2.2mm/ms 1400mm/500ms = 2.8mm/ms
DC Motor ネイティブ obniz&Li-Po 軽量化に大貢献 Li-Po 7.4V 400mAh DDC 5V
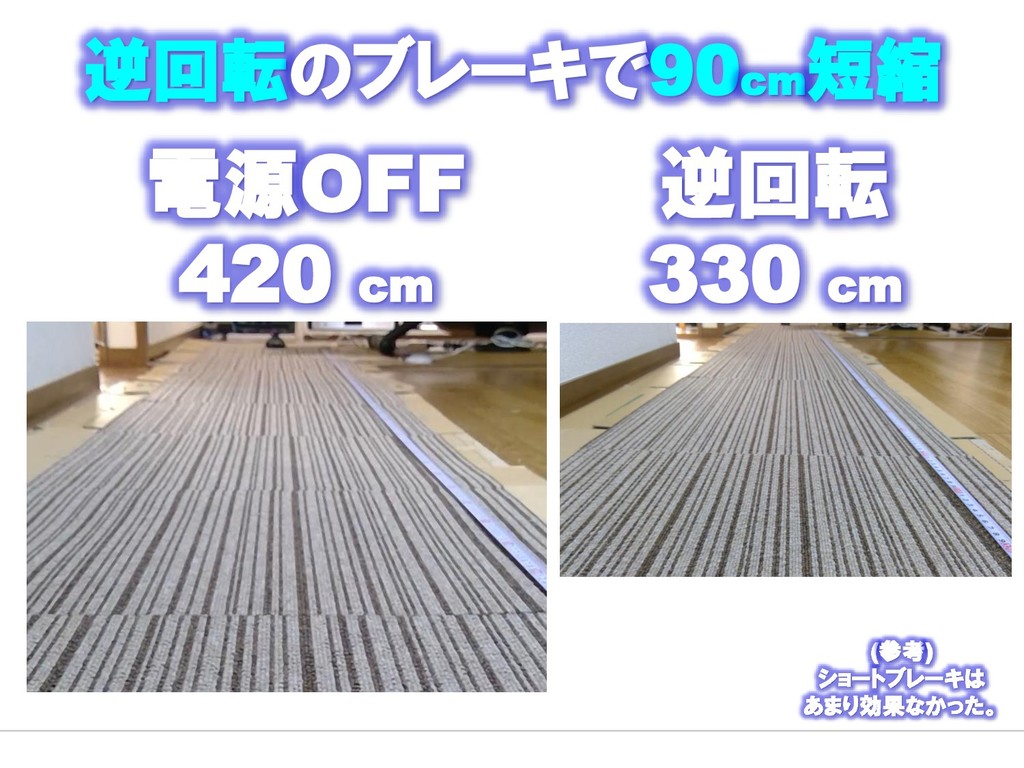
逆回転のブレーキで90cm 短縮 電源OFF 420 cm 逆回転 330 cm (参考) ショートブレーキは
あまり効果なかった。
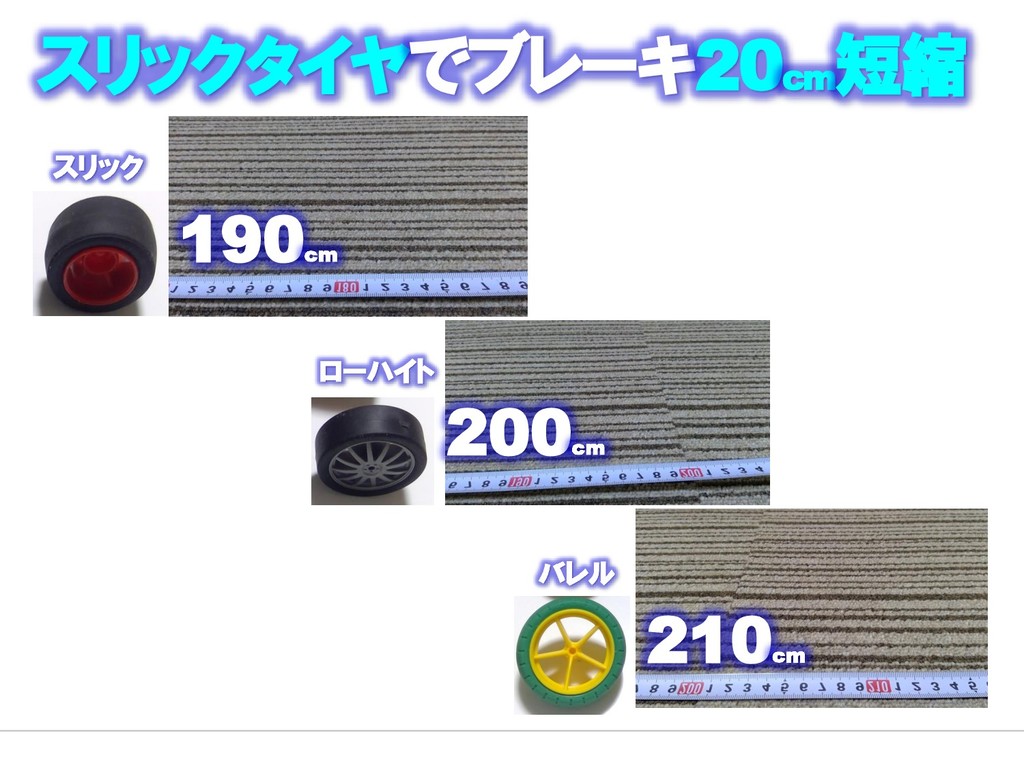
190cm スリックタイヤでブレーキ20cm 短縮 スリック ローハイト バレル 200cm 210cm
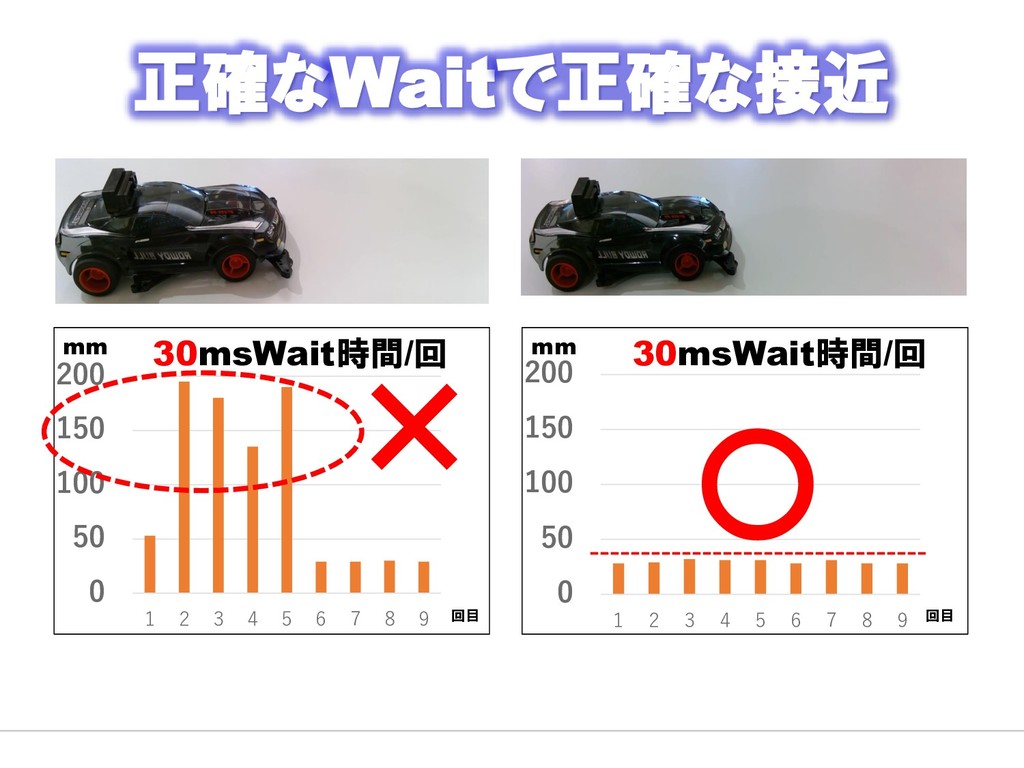
正確なWaitで正確な接近 0 50 100 150 200 1 2 3 4
5 6 7 8 9 0 50 100 150 200 1 2 3 4 5 6 7 8 9 mm mm 回目 回目 30msWait時間/回 30msWait時間/回 〇 ×
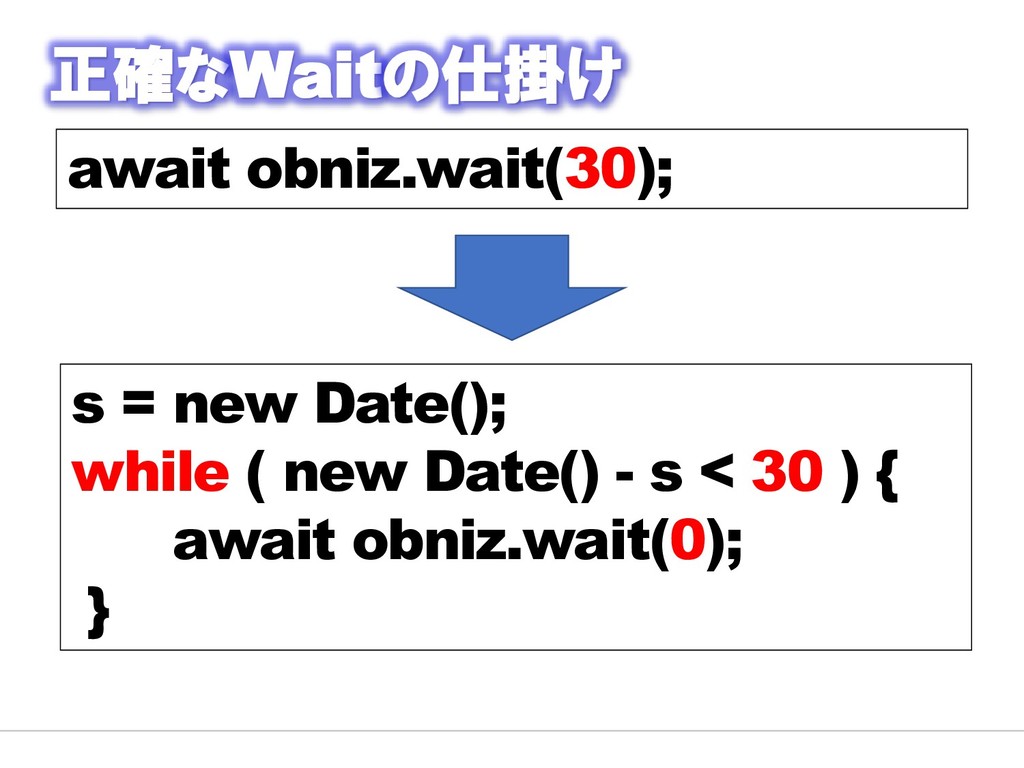
s = new Date(); while ( new Date() - s
< 30 ) { await obniz.wait(0); } await obniz.wait(30); 正確なWaitの仕掛け
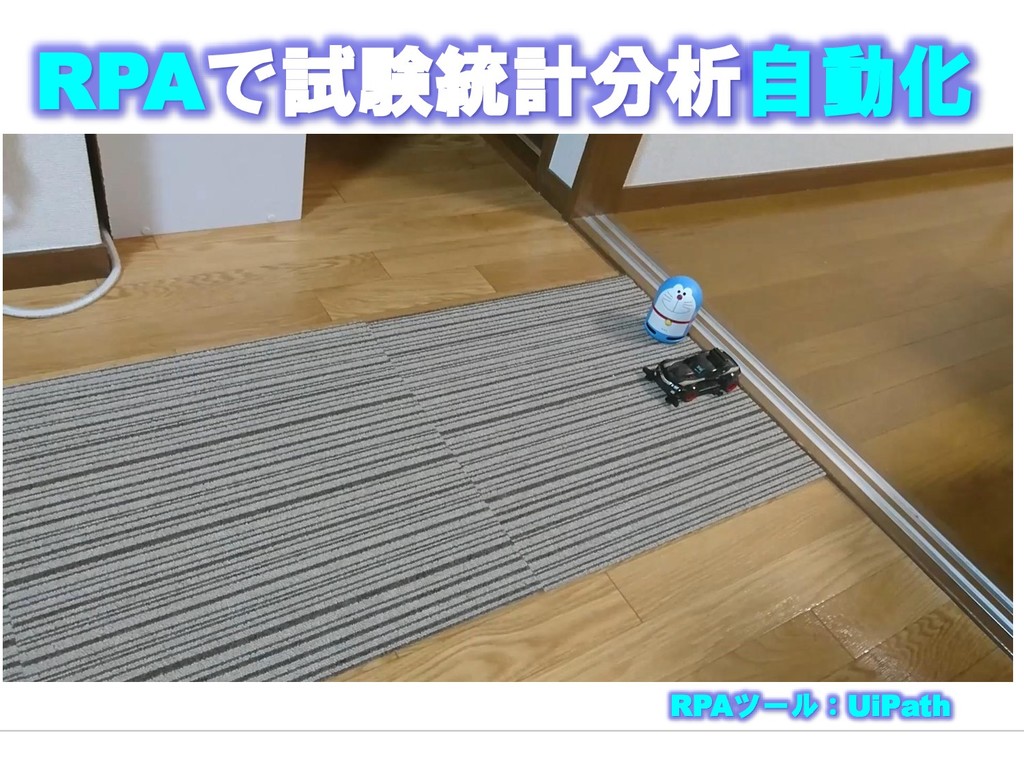
RPAで試験統計分析自動化 RPAツール:UiPath
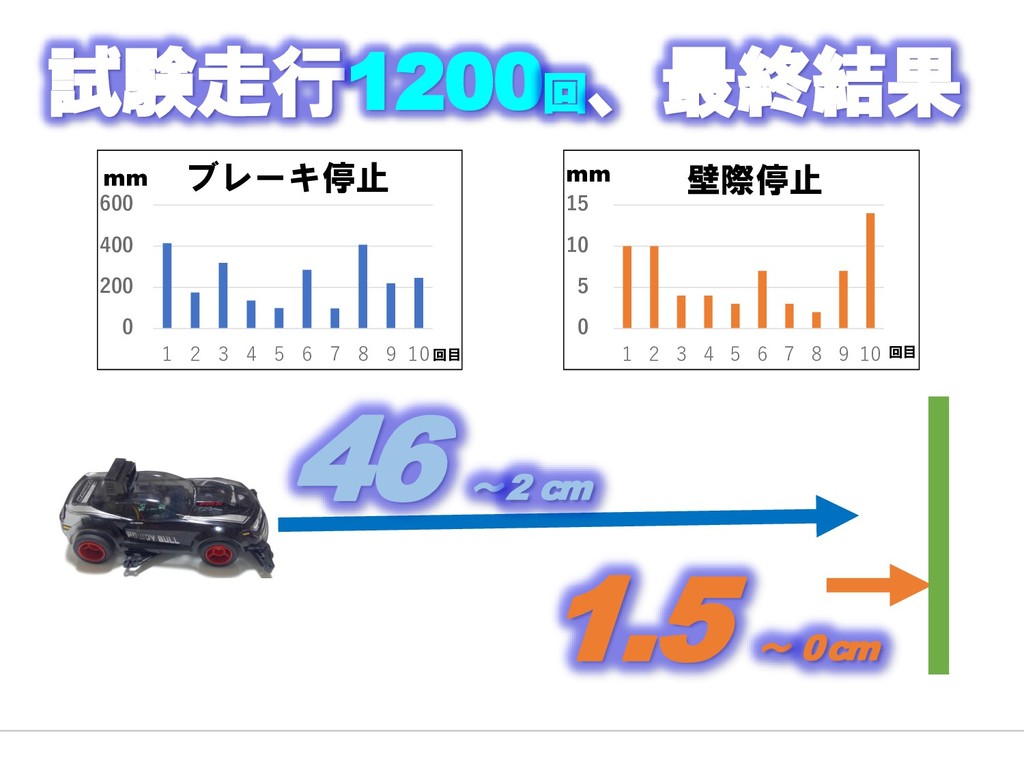
0 200 400 600 1 2 3 4 5 6
7 8 9 10 0 5 10 15 1 2 3 4 5 6 7 8 9 10 46 ~2 cm 1.5 ~ 0 cm ブレーキ停止 壁際停止 試験走行1200回 、最終結果 回目 回目 mm mm
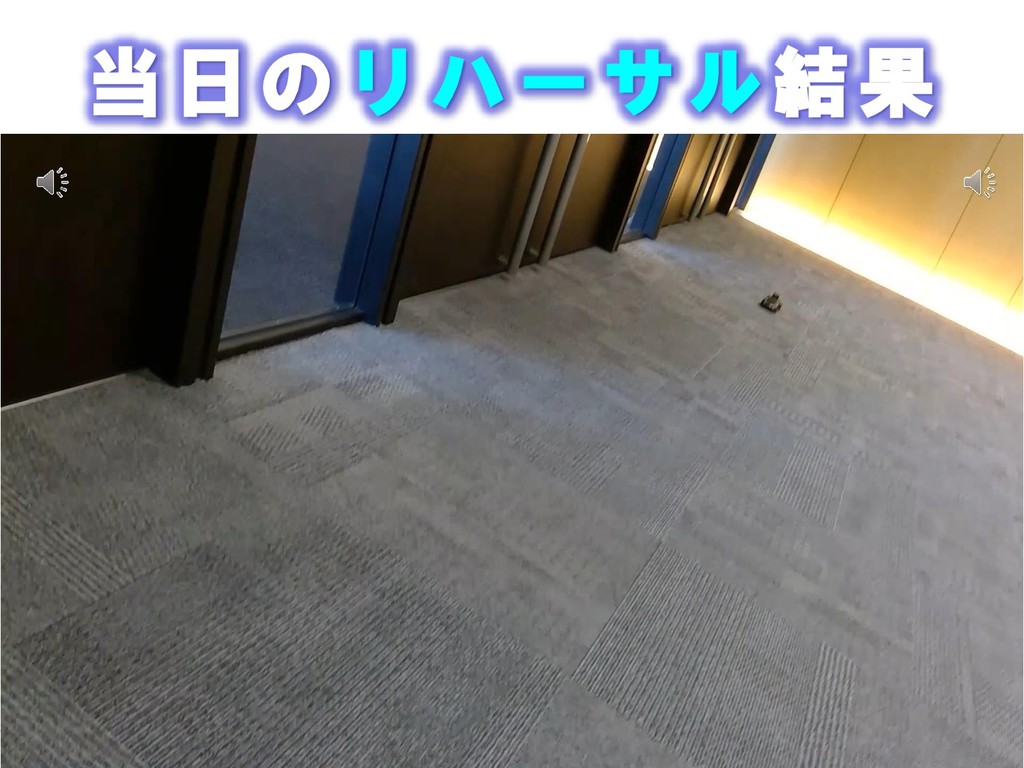
当日のリハーサル結果
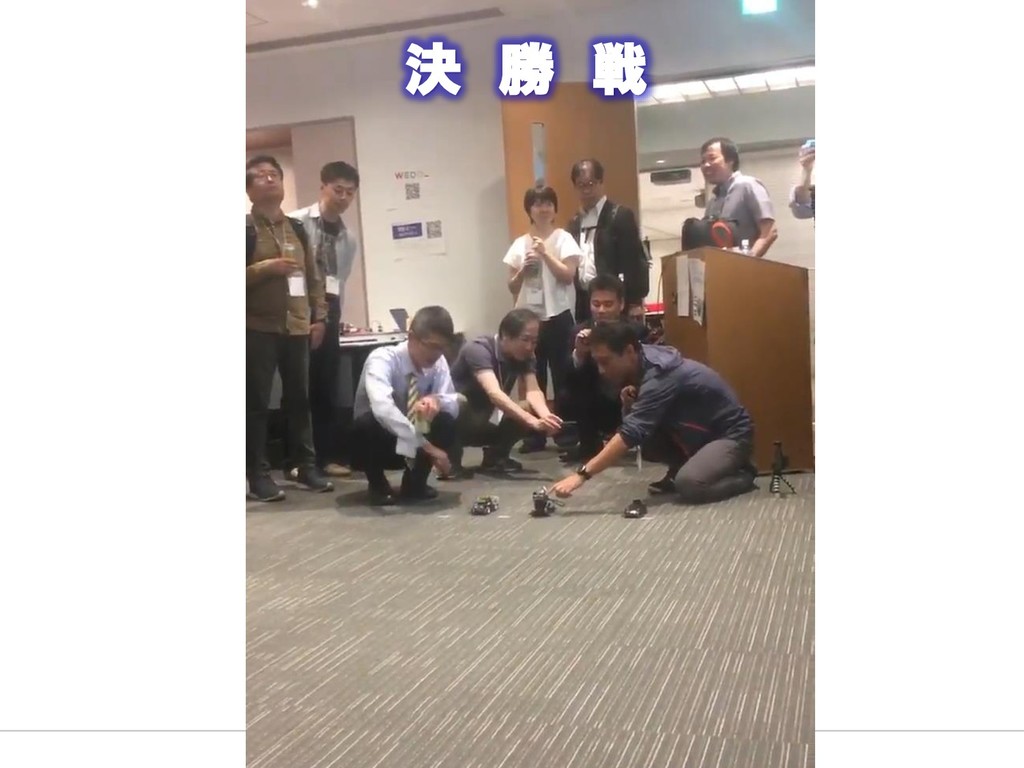
決 勝 戦
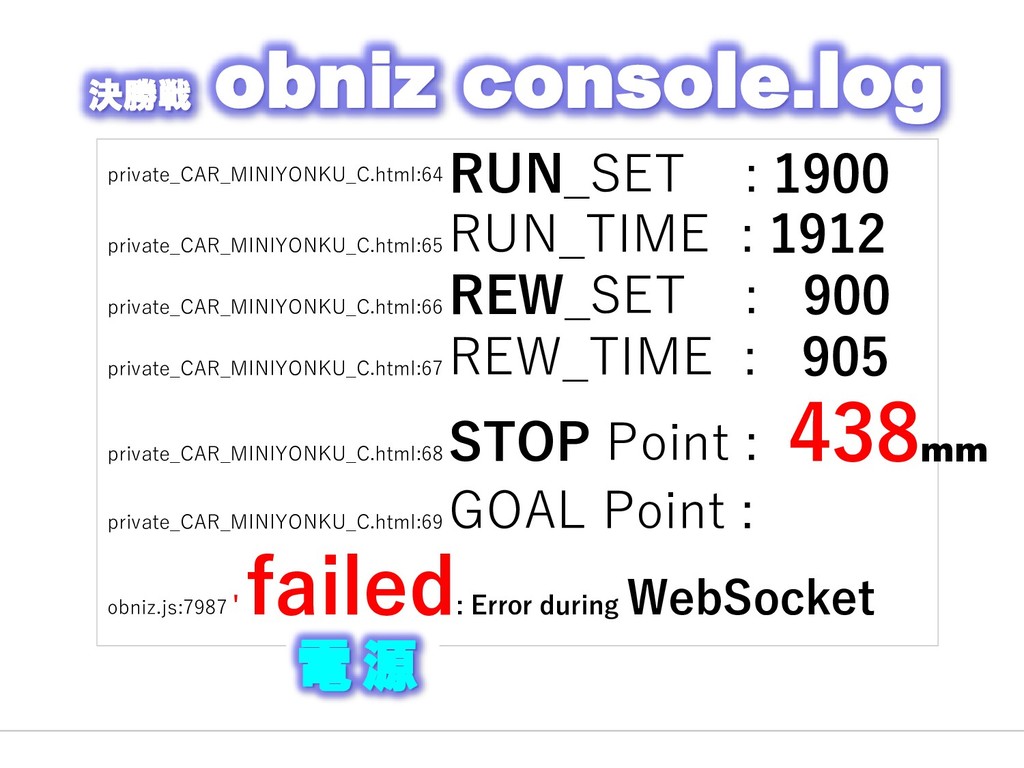
private_CAR_MINIYONKU_C.html:64 RUN_SET : 1900 private_CAR_MINIYONKU_C.html:65 RUN_TIME : 1912 private_CAR_MINIYONKU_C.html:66 REW_SET
: 900 private_CAR_MINIYONKU_C.html:67 REW_TIME : 905 private_CAR_MINIYONKU_C.html:68 STOP Point : 438 private_CAR_MINIYONKU_C.html:69 GOAL Point : obniz.js:7987 ' failed : Error during WebSocket 決勝戦 obniz console.log mm 電 源
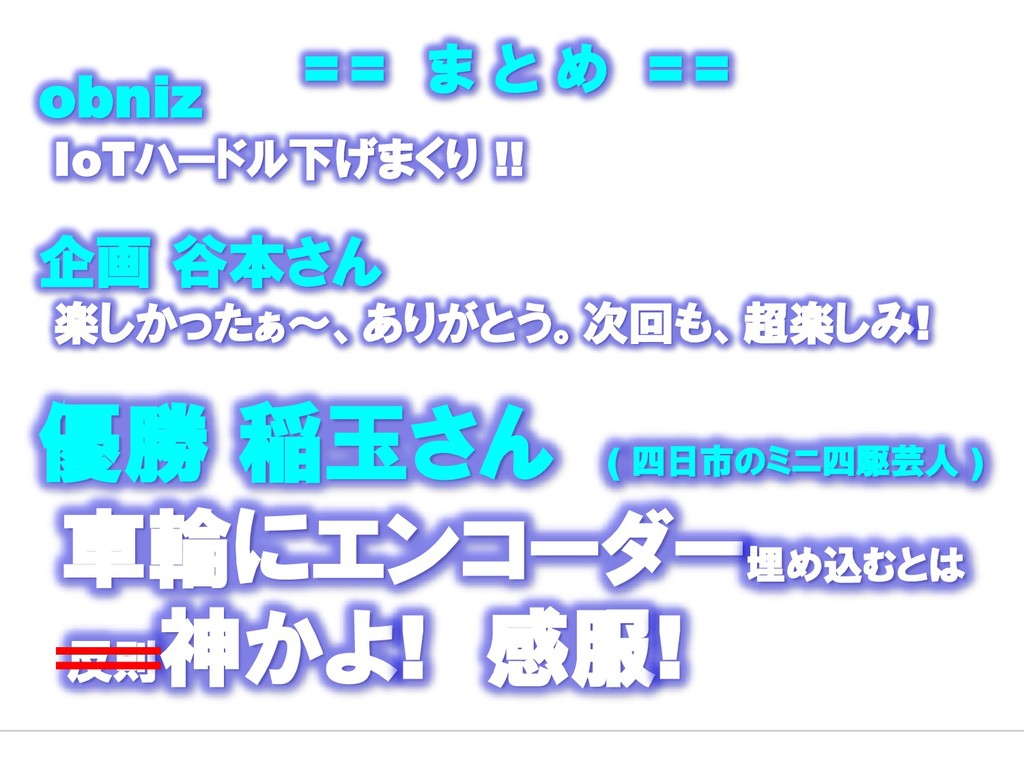
obniz IoTハードル下げまくり !! 企画 谷本さん 楽しかったぁ~、ありがとう。次回も、超楽しみ! 優勝 稲玉さん ( 四日市のミニ四駆芸人
) 車輪にエンコーダー埋め込むとは 反則 神かよ! 感服! = = ま と め = =


 googlehomer
 shisyu_gaku
 kinopeee
 maroon1st
 tsukuboshi
 kawaguti
 kintotechdev
 asmz
 mohab1
 reuven
 asanoharuki
 emiki
 zozotech
 kevinliebholz
 inesmontani
 uxyall
 letsgokoyo
 codingconduct
 coloredviolet
 ryanjones
 jonoalderson
 konakalab
 iamctodd
 sergeychernyshev
 danielanewman