Upgrade to Pro
— share decks privately, control downloads, hide ads and more …
Speaker Deck
Sign up for free
Menu
Search
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Features
All features
Private URLs
Password Protection
Custom URLS
Scheduled publishing
Remove Branding
Restrict embedding
Deck Collections
Notes
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Explore
Featured decks
Featured speakers
Programming
Technology
Storyboards
Pricing
Search
Sign in
Sign up for free
GR-ROSE でroombaをコントロールする
Search
lutecia16v
November 10, 2018
Technology
430
2
Share
Embed
Copy iframe code
Copy JS code
Copy link
Start on current slide
GR-ROSE でroombaをコントロールする
GR-ROSE プロデューサーミーティング (作品発表会)での発表資料です。
http://gadget.renesas.com/ja/event/2018/pm_rose2.html
lutecia16v
November 10, 2018
More Decks by lutecia16v
See All by lutecia16v
EDF-IDF Programming Guidを読む - JTAG Debugging 編 -
lutecia16v
1
420
GR-ROSEとROSを使ってコマンドサーボの現在位置をWebブラウザで表示してみる
lutecia16v
0
1.7k
GR-ROSEでROS/ROS2
lutecia16v
1
1.9k
Jetson NanoとGR-ROSEで始めるROS2
lutecia16v
0
2.3k
がじぇねるねでもROSしたい!
lutecia16v
1
160
Other Decks in Technology
See All in Technology
Agent × Maestro で始める モバイル E2E 端末準備からテスト実行・結果確認まで
sansantech
PRO
0
240
E2Eってつらくないですか?E2Eの管理コストを下げる手段とその実践
akaboshinit
6
2.8k
AI時代の開発はウォーターフォールに回帰する? / development-with-ai-back-to-wf
okamototakuyasr2
0
160
cdk deployとcdkd deploy、実際にデプロイして5倍速近くの差を実測した
yama3133
1
120
Vibe-to-Spec開発_実践ガイド
happysamurai294
0
120
Technical Project Manager の役割とやりがい、少しだけ AI
yoshiiryo1
0
280
正解のない研修に放り出されて / Being thrown into a training program with no right answers
ohnoeight
1
170
re:Inventで、人生は変わったのか? / growth-builders-hub-1-reinvent-2026
mhrtech
2
160
なぜ東京にいる私が、新潟の技術コミュニティを運営するのか by 八雲慎之助
yakumo
0
130
AWS Continuum for Penetration Testing に Deep Dive してみる
asanoharuki
2
1.5k
LLMの知識とAIエージェント
happysamurai294
0
130
OneLakeをデータソースにした AI Search(Foundry IQ)の ライフサイクル管理
ryuseiiida
0
200
Featured
See All Featured
[RailsConf 2023 Opening Keynote] The Magic of Rails
eileencodes
31
10k
HU Berlin: Industrial-Strength Natural Language Processing with spaCy and Prodigy
inesmontani
PRO
0
780
A Guide to Academic Writing Using Generative AI - A Workshop
ks91
PRO
1
540
The Impact of AI in SEO - AI Overviews June 2024 Edition
aleyda
6
1.2k
Bioeconomy Workshop: Dr. Julius Ecuru, Opportunities for a Bioeconomy in West Africa
akademiya2063
PRO
1
430
AI Search: Where Are We & What Can We Do About It?
aleyda
0
8.1k
Creating an realtime collaboration tool: Agile Flush - .NET Oxford
marcduiker
35
2.6k
GitHub's CSS Performance
jonrohan
1033
470k
Docker and Python
trallard
47
4.2k
Jess Joyce - The Pitfalls of Following Frameworks
techseoconnect
PRO
1
460
State of Search Keynote: SEO is Dead Long Live SEO
ryanjones
0
340
Done Done
chrislema
187
17k
Transcript
GR-ROSE でroombaを コントロールする - 2018 X’mas version - 2018.11.10 GR-ROSE作品発表会
るぅて(@lutecia16v)
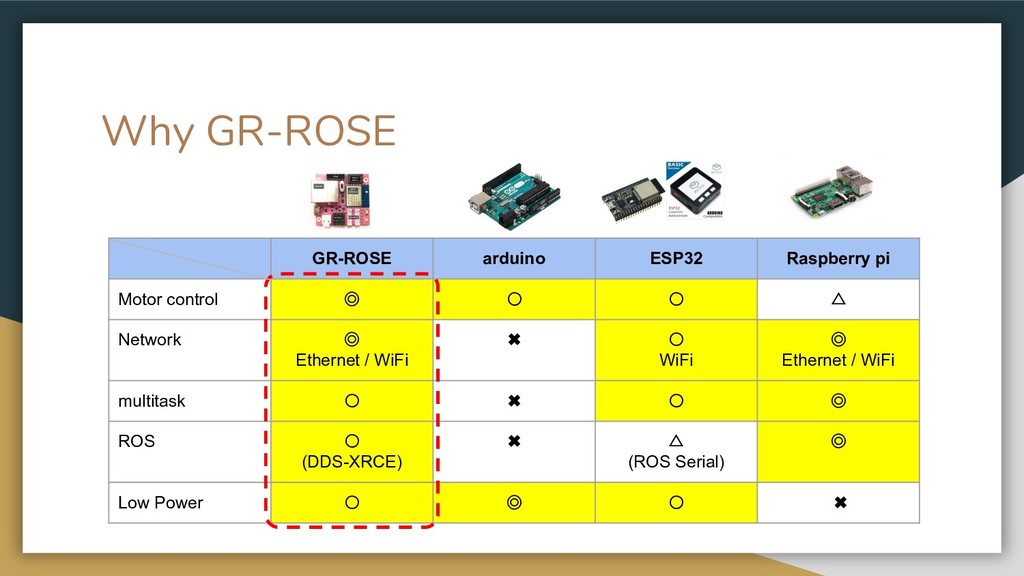
Why GR-ROSE GR-ROSE arduino ESP32 Raspberry pi Motor control ◎
〇 〇 △ Network ◎ Ethernet / WiFi ✖ 〇 WiFi ◎ Ethernet / WiFi multitask 〇 ✖ 〇 ◎ ROS 〇 (DDS-XRCE) ✖ △ (ROS Serial) ◎ Low Power 〇 ◎ 〇 ✖
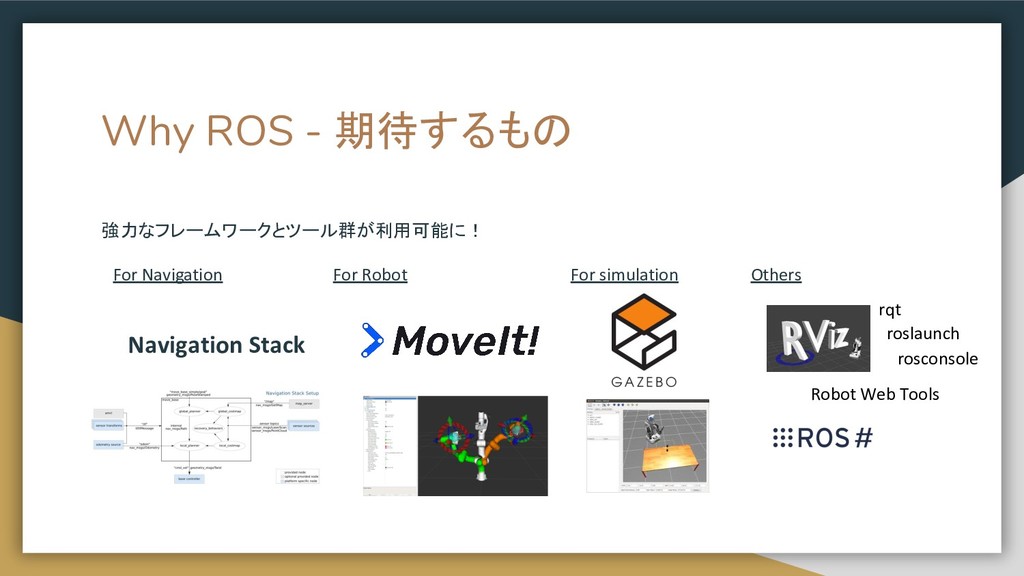
Why ROS - 期待するもの 強力なフレームワークとツール群が利用可能に! For Navigation For Robot For
simulation Navigation Stack Others rqt rosconsole roslaunch Robot Web Tools
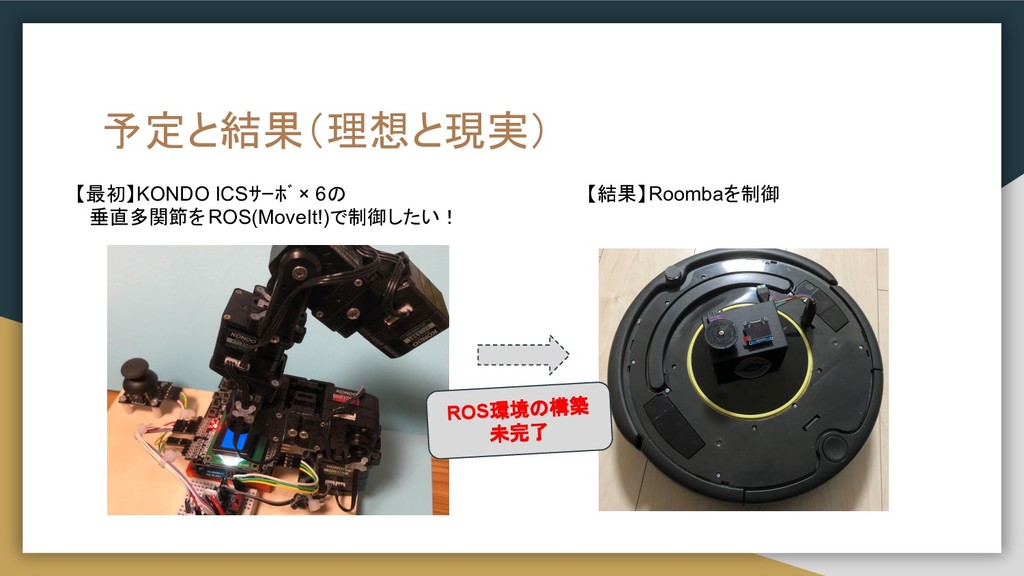
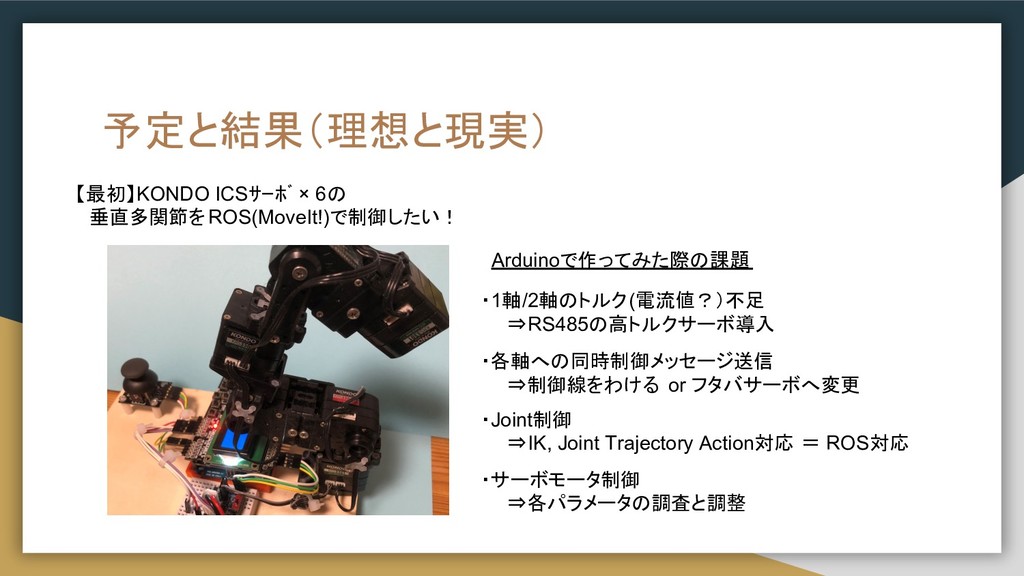
予定と結果(理想と現実) 【最初】KONDO ICSサーボ × 6の 垂直多関節をROS(MoveIt!)で制御したい! 【結果】Roombaを制御 ROS環境の構築 未完了
予定と結果(理想と現実) 【最初】KONDO ICSサーボ × 6の 垂直多関節をROS(MoveIt!)で制御したい! Arduinoで作ってみた際の課題 ・1軸/2軸のトルク(電流値?)不足 ⇒RS485の高トルクサーボ導入 ・Joint制御
⇒IK, Joint Trajectory Action対応 = ROS対応 ・サーボモータ制御 ⇒各パラメータの調査と調整 ・各軸への同時制御メッセージ送信 ⇒制御線をわける or フタバサーボへ変更
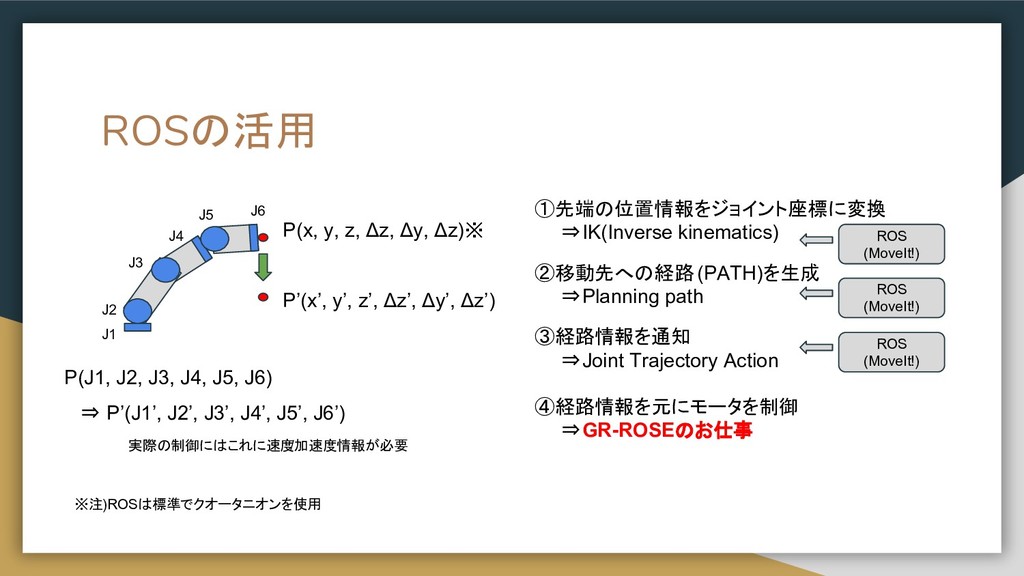
ROSの活用 J1 J2 J3 J4 J5 J6 P(x, y, z,
Δz, Δy, Δz)※ P’(x’, y’, z’, Δz’, Δy’, Δz’) P(J1, J2, J3, J4, J5, J6) ①先端の位置情報をジョイント座標に変換 ⇒IK(Inverse kinematics) ②移動先への経路(PATH)を生成 ⇒Planning path ③経路情報を通知 ⇒Joint Trajectory Action ④経路情報を元にモータを制御 ⇒GR-ROSEのお仕事 ※注)ROSは標準でクオータニオンを使用 ROS (MoveIt!) ROS (MoveIt!) ROS (MoveIt!) ⇒ P’(J1’, J2’, J3’, J4’, J5’, J6’) 実際の制御にはこれに速度 /加速度情報が必要
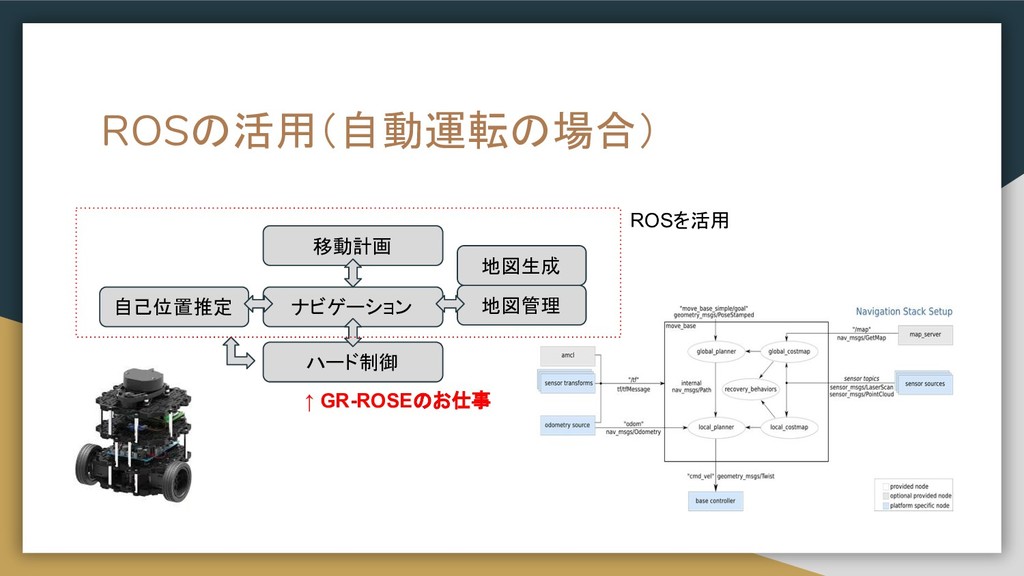
ROSの活用(自動運転の場合) 移動計画 ナビゲーション 自己位置推定 地図管理 ハード制御 地図生成 ↑ GR-ROSEのお仕事 ROSを活用
さて本題
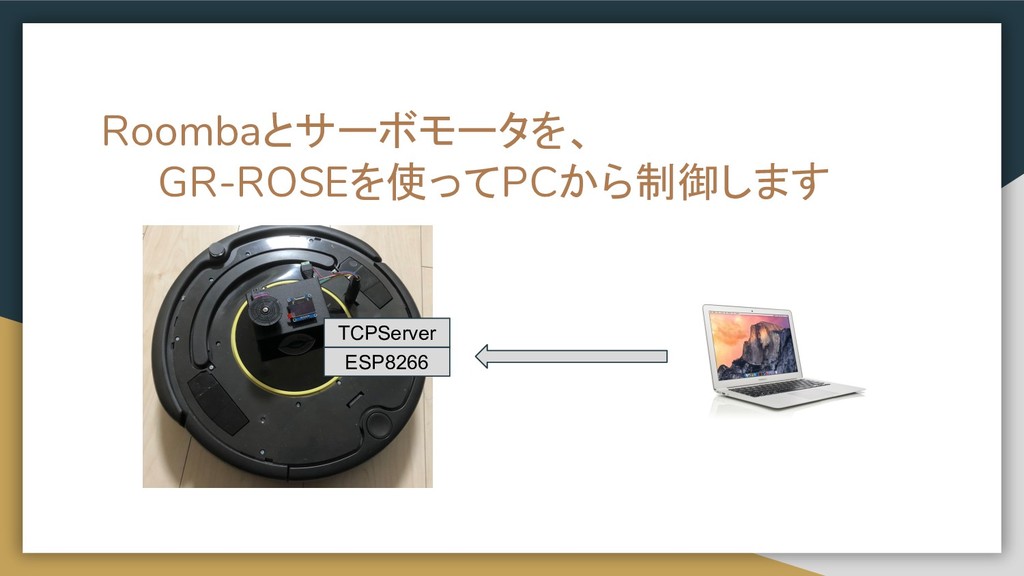
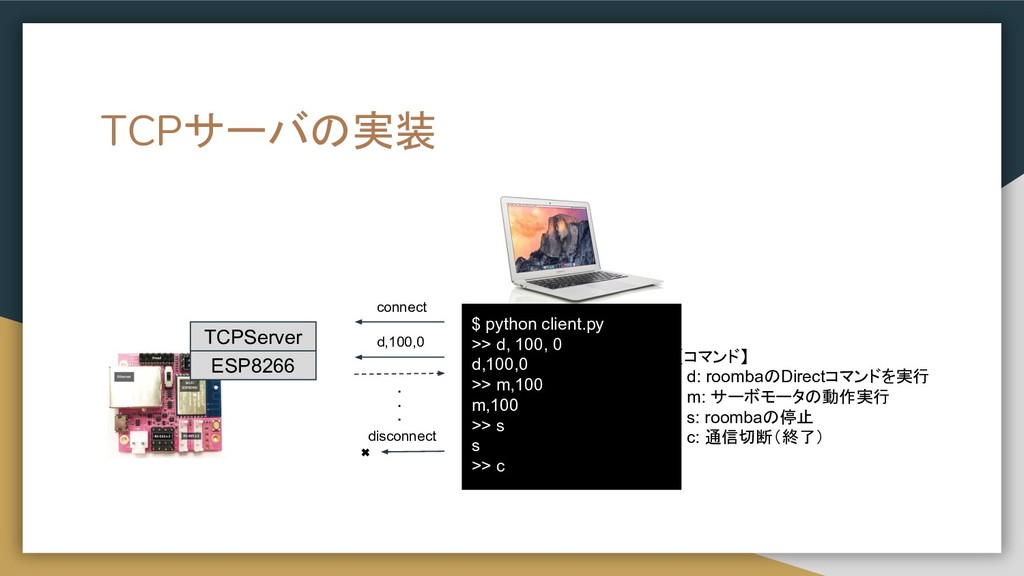
Roombaとサーボモータを、 GR-ROSEを使ってPCから制御します ESP8266 TCPServer
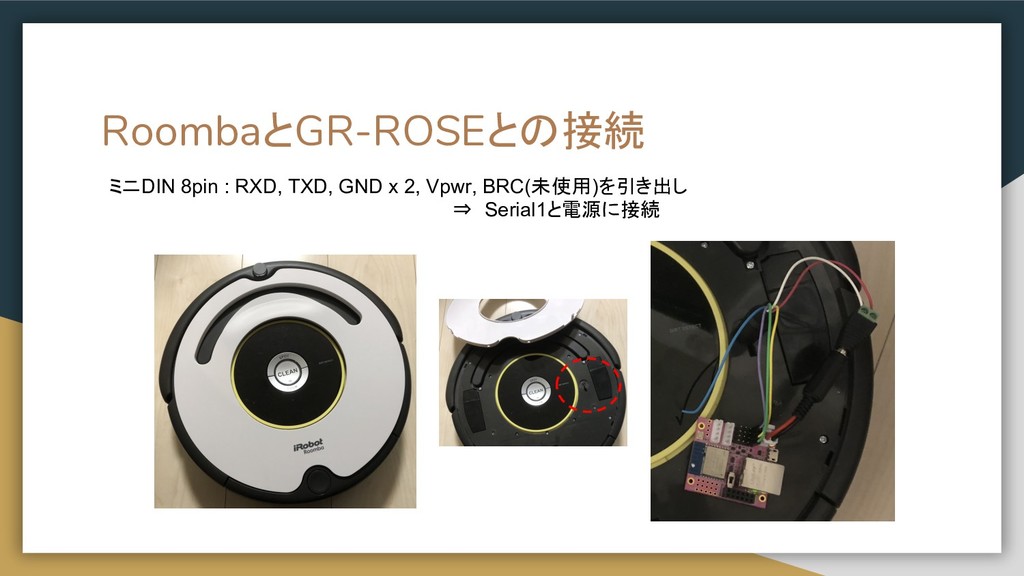
RoombaとGR-ROSEとの接続 ミニDIN 8pin : RXD, TXD, GND x 2, Vpwr,
BRC(未使用)を引き出し ⇒ Serial1と電源に接続
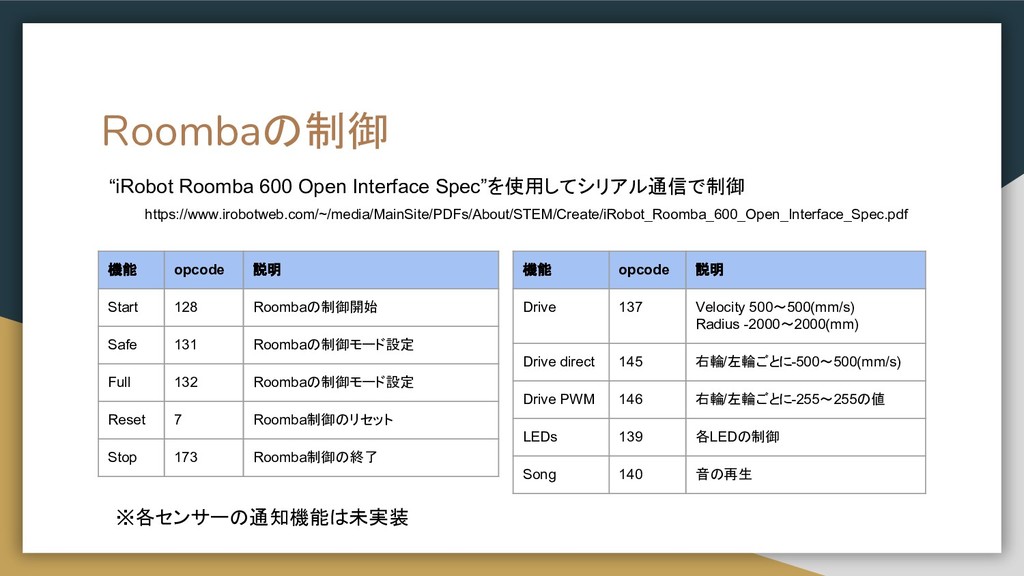
Roombaの制御 “iRobot Roomba 600 Open Interface Spec”を使用してシリアル通信で制御 https://www.irobotweb.com/~/media/MainSite/PDFs/About/STEM/Create/iRobot_Roomba_600_Open_Interface_Spec.pdf 機能 opcode
説明 Start 128 Roombaの制御開始 Safe 131 Roombaの制御モード設定 Full 132 Roombaの制御モード設定 Reset 7 Roomba制御のリセット Stop 173 Roomba制御の終了 機能 opcode 説明 Drive 137 Velocity 500~500(mm/s) Radius -2000~2000(mm) Drive direct 145 右輪/左輪ごとに-500~500(mm/s) Drive PWM 146 右輪/左輪ごとに-255~255の値 LEDs 139 各LEDの制御 Song 140 音の再生 ※各センサーの通知機能は未実装
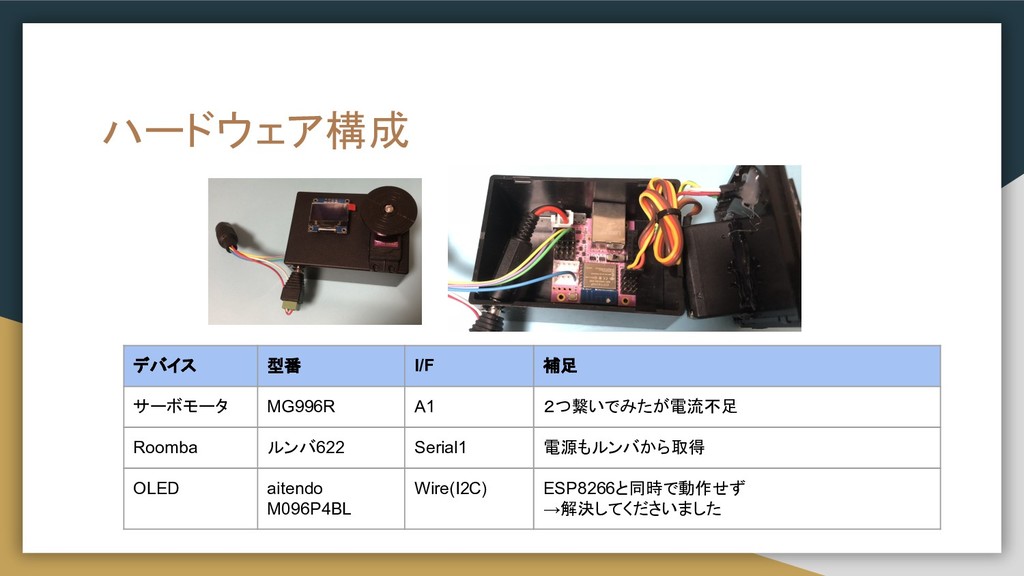
ハードウェア構成 デバイス 型番 I/F 補足 サーボモータ MG996R A1 2つ繋いでみたが電流不足 Roomba
ルンバ622 Serial1 電源もルンバから取得 OLED aitendo M096P4BL Wire(I2C) ESP8266と同時で動作せず →解決してくださいました
disconnect TCPサーバの実装 ESP8266 TCPServer $ python client.py >> d, 100,
0 d,100,0 >> m,100 m,100 >> s s >> c 【コマンド】 d: roombaのDirectコマンドを実行 m: サーボモータの動作実行 s: roombaの停止 c: 通信切断(終了) connect d,100,0 ・ ・ ・ ✖
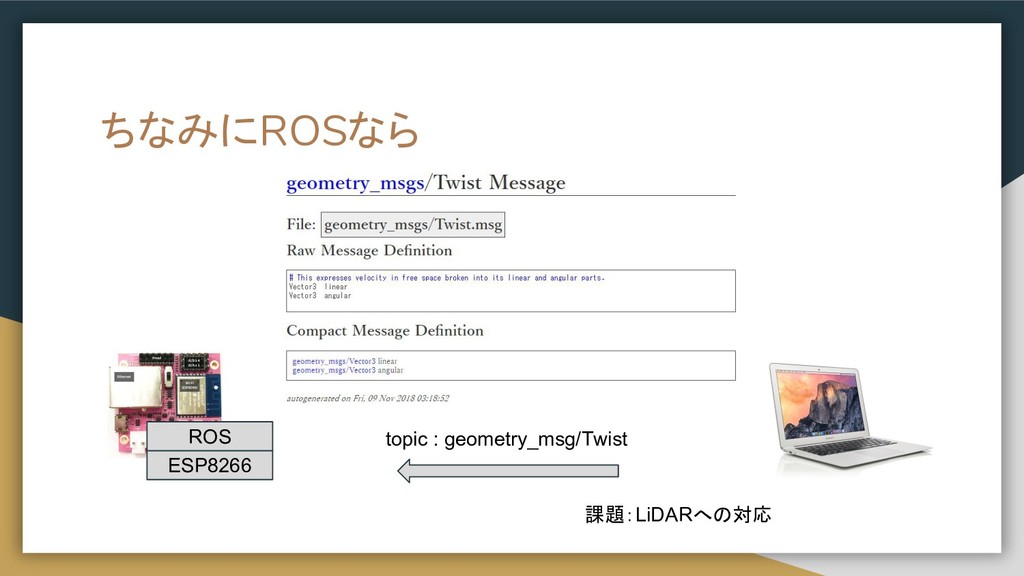
ちなみにROSなら ESP8266 ROS topic : geometry_msg/Twist 課題:LiDARへの対応
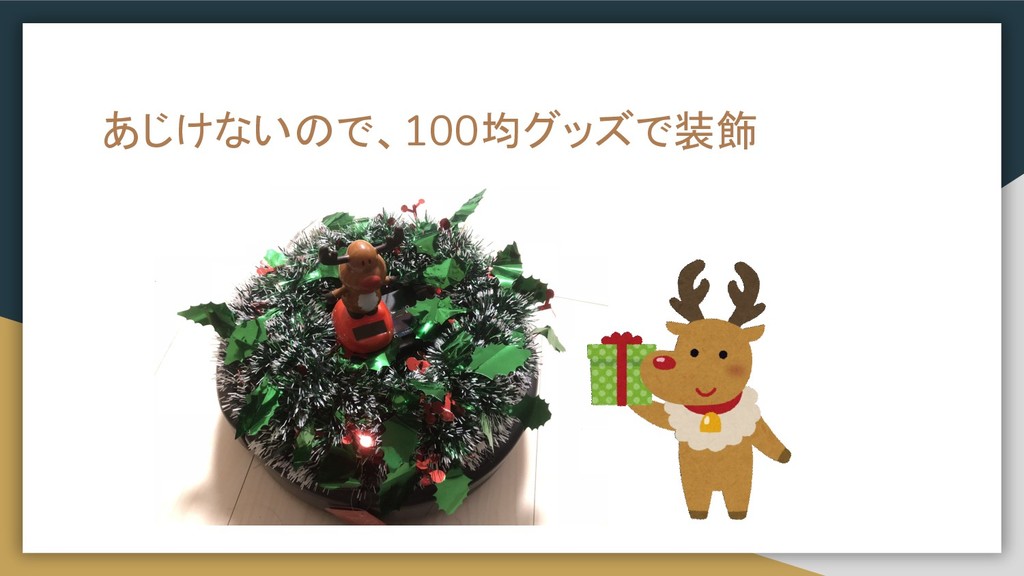
あじけないので、100均グッズで装飾


 lutecia16v
 sansantech
 akaboshinit
 okamototakuyasr2
 yama3133
 happysamurai294
 yoshiiryo1
 ohnoeight
 mhrtech
 yakumo
 asanoharuki
 ryuseiiida
 eileencodes
 inesmontani
 ks91
 aleyda
 akademiya2063
 marcduiker
 jonrohan
 trallard
 techseoconnect
 ryanjones
 chrislema